Obstacle avoidance
خۆلادان لە بەربەست
Proposed Kurdish term — under reviewزاراوەی پێشنیارکراو — لە ژێر پێداچوونەوەدایە Definitionپێناسە
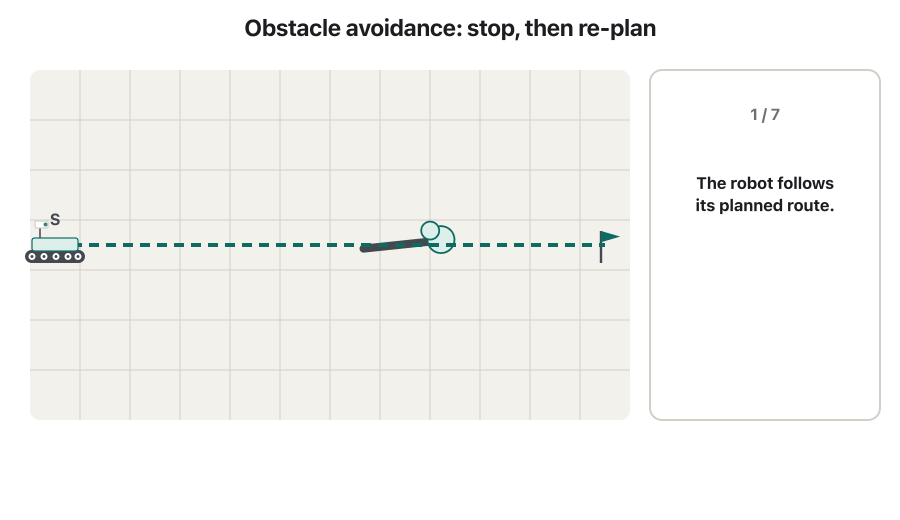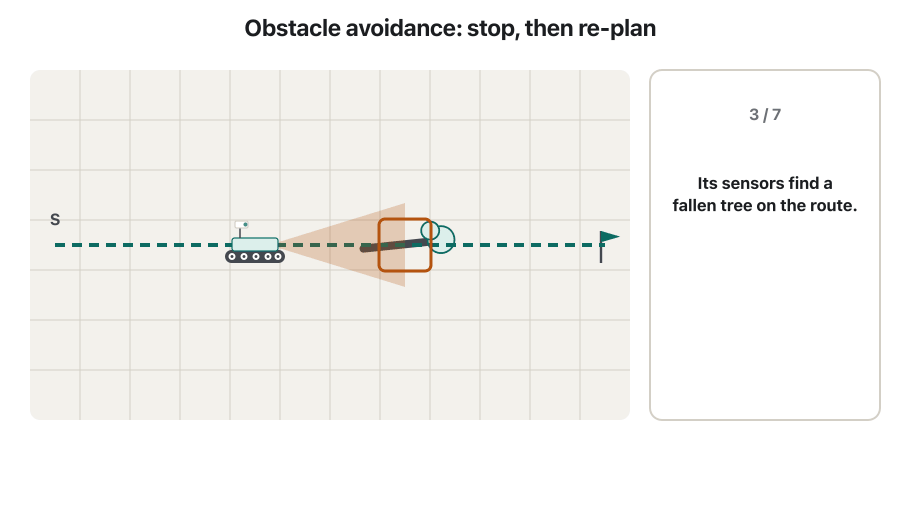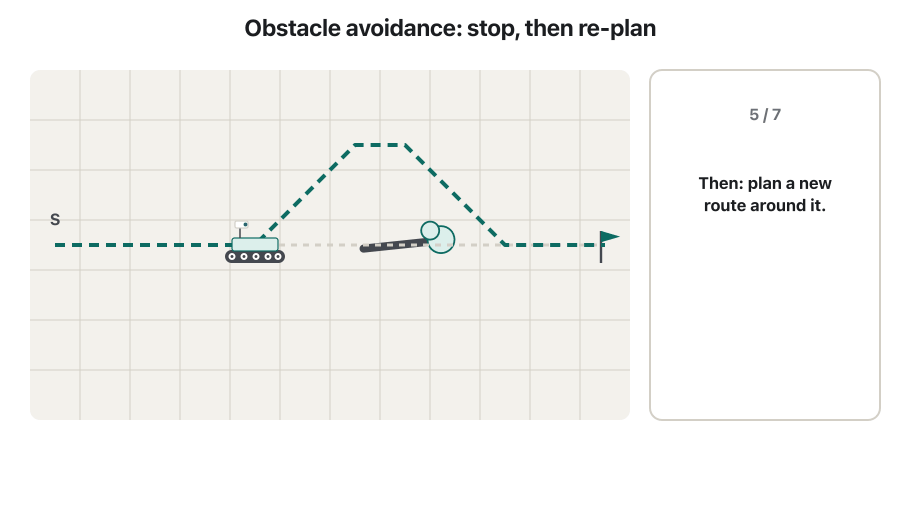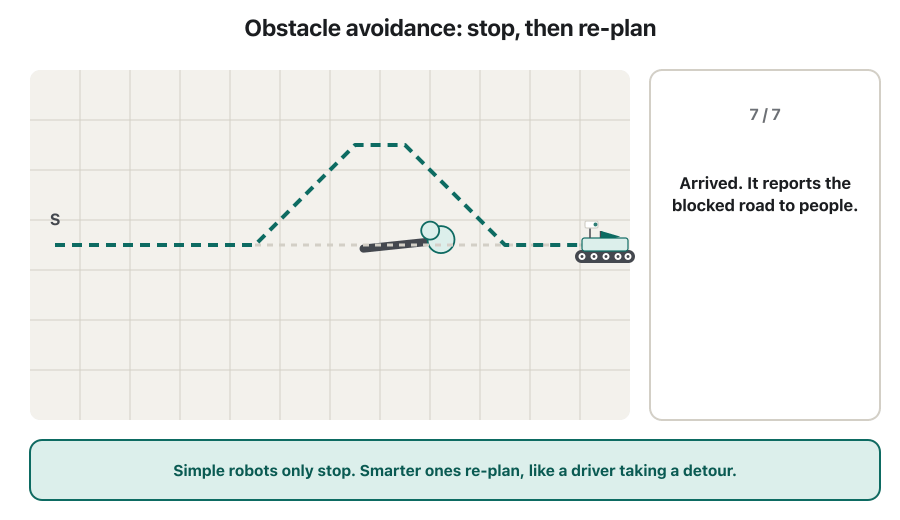
A machine's ability to notice things in its way with cameras, or other , and to stop or change its path so that it does not hit them.
توانای ئامێرێکە کە بە کامێرا، یان تر هەست بەو شتانە بکات کە لە ڕێگەیدان و بوەستێت یان ڕێگەکەی بگۆڕێت بۆ ئەوەی بەریان نەکەوێت.
Picturesوێنەکان
Exampleنموونە
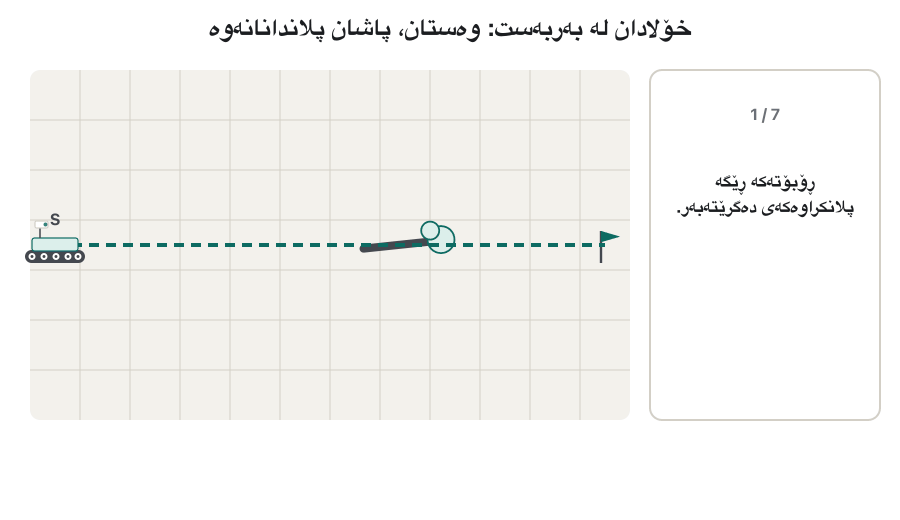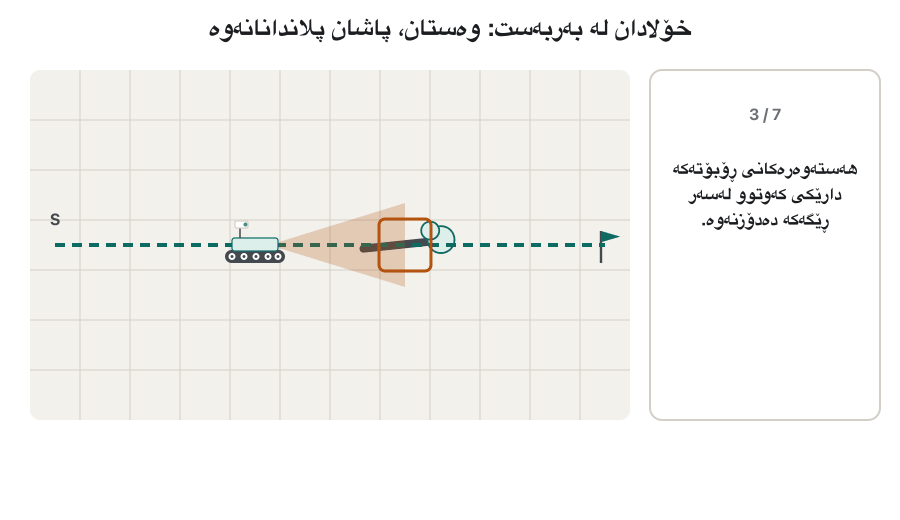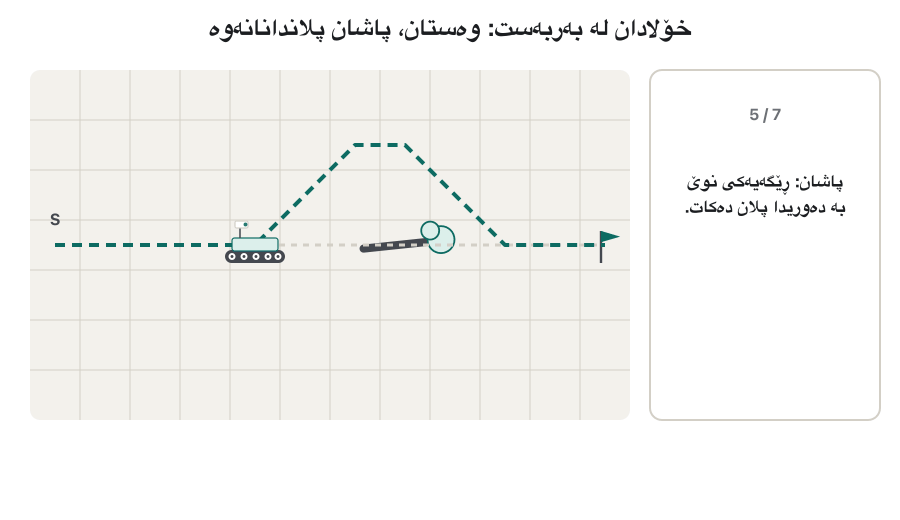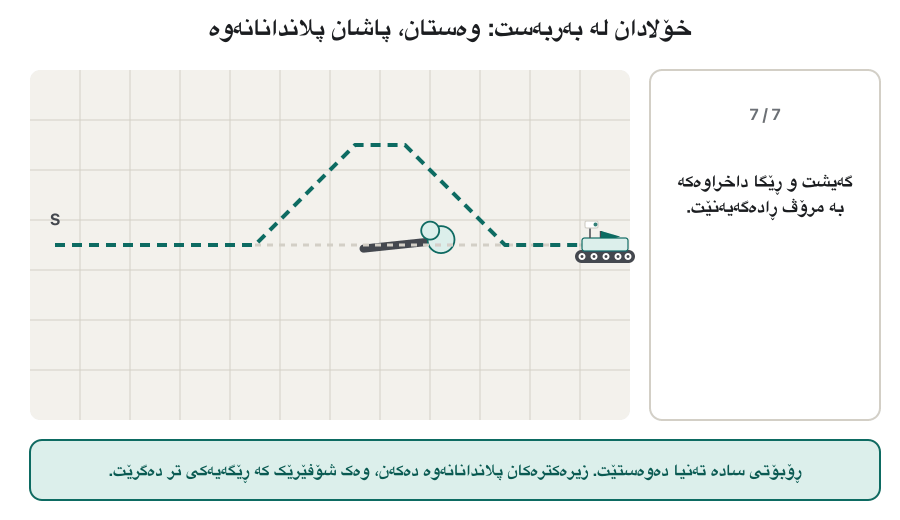
A ground robot finds a fallen tree on its route, stops, plans a way around it and continues.
زەمینی دارێکی کەوتوو لەسەر ڕێگاکەی دەبینێت، دەوەستێت، ڕێگایەک بە دەوریدا پلان دەکات و بەردەوام دەبێت.
Note on the Kurdish termتێبینی لەبارەی زاراوە کوردییەکە
Proposed: خۆلادان (turning aside, avoiding) + بەربەست (obstacle). Same id as PLAN-DRN's planned obstacle-avoidance (drone-autonomy-and-the-future). Marked everyday.
Related termsزاراوە پەیوەندیدارەکان
Learn more inزیاتر فێربە لە
- Autonomous Drones, Vehicles and Robotsدرۆن، ئۆتۆمبێل و ڕۆبۆتی سەربەخۆ
- Autonomy, Swarms, Air Taxis and the Future of Dronesسەربەخۆیی، ڕەوەکانی درۆن، تەکسییە ئاسمانییەکان و داهاتووی درۆنەکان
- The Flight Controller: Sensors, Control Loops and Autopilotsکۆنترۆڵکەری فڕین: هەستەوەرەکان، خولەکانی کۆنترۆڵ و فڕۆکەوانی خۆکار