Chapterبەش 2 · Lectureوانە 2.2
How a Quadcopter Flies: Forces, Torque, Pitch, Roll and Yawچوارپەروانە چۆن دەفڕێت: هێزەکان، زەبر، لێژی، لاربوونەوە و سووڕانەوەی ئاسۆیی
The physics of a quadcopter: what "aerodynamic" means, the four forces, how a spinning propeller makes thrust (and why the "equal transit time" story is wrong), hovering with , why neighbouring rotors spin opposite ways, how changing rotor speeds makes the drone climb, pitch, roll and yaw, the three axes and the Mode 2 sticks, and why thin air and wind matter.
فیزیای : واتە چی، چوار ، سووڕاو چۆن دروست دەکات (و بۆچی چیرۆکی «کاتی تێپەڕینی یەکسان» هەڵەیە)، بە ، بۆچی دراوسێ بە پێچەوانەی یەک دەسووڕێنەوە، گۆڕینی خێرایی چۆن بەرز دەکاتەوە و ، و دروست دەکات، سێ و دەسکەکانی Mode 2، هەروەها بۆچی هەوای تەنک و با گرنگن.
What you will learnچی فێر دەبیت
- Explain what "aerodynamic" means and name the four forces that act on a drone.
- Explain how a propeller makes thrust by turning air downwards, without the "equal transit time" myth.
- Work out the thrust needed to hover with .
- Explain why neighbouring rotors spin opposite ways, and say which rotors speed up to climb, pitch, roll and yaw.
- Match the three axes to the sticks of a Mode 2 controller, and explain the effect of thin air and wind.
- ڕوونی بکەیتەوە واتە چی و ناوی ئەو چوار بهێنیت کە کار دەکەنە سەر .
- ڕوونی بکەیتەوە چۆن بە لادانی هەوا بەرەو خوارەوە دروست دەکات، بەبێ ئەفسانەی «کاتی تێپەڕینی یەکسان».
- ئەو بۆ پێویستە بە بدۆزیتەوە.
- ڕوونی بکەیتەوە بۆچی دراوسێ بە پێچەوانەی یەک دەسووڕێنەوە و بڵێیت کام بۆ بەرزبوونەوە، ، و خێرا دەبن.
- سێ لەگەڵ دەسکەکانی بە شێوەی Mode 2 بگونجێنیت و کاریگەریی هەوای تەنک و با ڕوون بکەیتەوە.
What does “aerodynamic” mean?ئایرۆدینامیکی واتە چی؟
Aerodynamics is the study of how air moves around things, especially things that move fast, like cars, planes, birds, rockets and drones. When something is aerodynamic, it can move through the air easily: the air does not slow it down much, so it uses less energy or fuel just because of its shape.
زانستی جووڵەی هەوایە بە دەوری شتەکاندا، بەتایبەتی ئەو شتانەی خێرا دەجووڵێن، وەک ئۆتۆمبێل، فڕۆکە، باڵندە، مووشەک و . کاتێک شتێک بێت، بە ئاسانی بە ناو هەوادا دەجووڵێت: هەوا زۆر هێواشی ناکاتەوە، بۆیە تەنیا بەهۆی شێوەکەیەوە وزە یان سووتەمەنیی کەمتر بەکار دەهێنێت.
A blunt shape leaves a big wake of swirling air behind it, and making that wake costs energy. A smooth, rounded shape lets the air close up behind it. For a drone, aerodynamics matters twice: its propellers are carefully shaped little wings, and a smooth body wastes less battery when the drone flies fast.
شێوەیەکی ڕووپان گێژاوێکی گەورەی هەوا لە دواوەی خۆیدا بەجێ دەهێڵێت و دروستکردنی ئەو گێژاوە وزەی دەوێت. شێوەیەکی نەرم و خڕ ڕێگە دەدات هەوا لە دواوەیدا بگاتەوە یەک. بۆ ، دوو جار گرنگە: باڵی بچووکی بە وردی شێوەدارن و لاشەیەکی نەرم کاتێک بە خێرایی دەفڕێت، کەمتر بە فیڕۆ دەدات.
The study of how air moves around things that move through it, such as planes, birds, cars and drones. An aerodynamic shape lets the air flow past easily, so the air slows it down less and it uses less energy.
زانستی جووڵەی هەوایە بە دەوری ئەو شتانەدا کە بە ناویدا دەجووڵێن، وەک فڕۆکە، باڵندە، ئۆتۆمبێل و . شێوەیەکی ئایرۆدینامیکی ڕێگە دەدات هەوا بە ئاسانی بە لایدا تێپەڕێت، بۆیە هەوا کەمتر هێواشی دەکاتەوە و وزەی کەمتر بەکار دەهێنێت.
Four forcesچوار هێزەکە
Four forces act on every aircraft. Weight pulls it down toward the centre of the Earth. Lift holds it up. Thrust pushes it along. Drag, the resistance of the air, pulls back against the motion. When the forces are balanced, the aircraft keeps a steady speed, or a drone hovers in place. When they are not balanced, it speeds up in the direction of the bigger force.
چوار کار دەکەنە سەر هەموو فڕۆکەیەک. بەرەو ناوەڕاستی زەوی ڕایدەکێشێت. بە بەرزی ڕایدەگرێت. بەرەو پێشی دەبات. ، کە بەرهەڵستیی هەوایە، بە پێچەوانەی جووڵەکە ڕایدەکێشێتەوە. کاتێک هاوسەنگ بن، فڕۆکەکە بە خێراییەکی جێگیر دەڕوات، یان لە شوێنی خۆیدا لە هەوادا ڕادەوەستێت. کاتێک هاوسەنگ نەبن، بەرەو ئاڕاستەی خێراتر دەبێت.
A fixed-wing drone gets its lift from its wings, while its propeller pulls it forward. A multirotor has no wings: its rotors' thrust points up and does the job of lift; to move, the drone tilts, so part of that thrust pushes it along. Types of drones compares the two families.
لە باڵەکانییەوە وەردەگرێت، لە کاتێکدا بەرەو پێش ڕایدەکێشێت. باڵی نییە: بەرەو سەرەوەیە و کاری دەکات؛ بۆ جووڵە، لار دەبێتەوە بۆ ئەوەی بەشێک لەو بەرەو پێشی بەرێت. جۆرەکانی درۆن ئەم دوو خێزانە بەراورد دەکات.
How a propeller pushes airپەروانە چۆن هەوا پاڵ دەنێت
Each blade of a propeller is a small wing that spins. It meets the air at a slight angle and turns the air downwards. By Newton's third law, if the blade pushes the air down, the air pushes the blade up just as hard. You can also see it as pressure: the air just above the blades has lower pressure and the air below has higher pressure, so the blades are pushed up. Both explanations describe the same airflow.
هەر پەڕەیەکی باڵێکی بچووکە کە دەسووڕێتەوە. بە گۆشەیەکی کەم بەر هەوا دەکەوێت و هەوا بەرەو خوارەوە لا دەدات. بەپێی ، ئەگەر پەڕەکە هەوا بەرەو خوارەوە پاڵ بنێت، هەوا بە هەمان بەهێزی پەڕەکە بەرەو سەرەوە پاڵ دەنێت. دەتوانیت وەک پەستانیش سەیری بکەیت: هەوای ڕاستەوخۆ سەرووی پەڕەکان کەمترە و هەوای خوارەوەیان زیاترە، بۆیە پەڕەکان بەرەو سەرەوە پاڵ دەنرێن. هەردوو ڕوونکردنەوەکە باسی هەمان ڕەوتی هەوا دەکەن.
All the blade forces together make the propeller's thrust, along its shaft. The fast stream of air under a hovering drone is called prop wash: you feel it on your face and see it blow dust and grass.
هەموو سەر پەڕەکان پێکەوە دروست دەکەن، بە درێژایی میلەکەی. ئەو ڕەوتە خێرایەی هەوا کە لە ژێر ڕاوەستاو هەیە پێی دەڵێن prop wash: لەسەر ڕوخسارت هەستی پێ دەکەیت و دەبینیت تۆز و گیا هەڵدەفڕێنێت.
How a propeller pushes airپەروانە چۆن هەوا پاڵ دەنێت
Not the "equal transit time" storyنەک چیرۆکی «کاتی تێپەڕینی یەکسان»
Hovering: thrust equals weightڕاوەستان لە هەوادا: هێزی پاڵنەر یەکسانە بە کێش
To stay still in the air at one place and one height. A drone hovers when its total equals its and the thrust points straight up.
مانەوەیە بە جێگیری لە هەوادا، لە یەک شوێن و لە یەک . لە هەوادا ڕادەوەستێت کاتێک کۆی یەکسان بێت بە و هێزی پاڵنەرەکە ڕاست بەرەو سەرەوە بێت.
To hover, the drone's total thrust must point straight up and equal its weight. Weight is a force: the mass times the pull of gravity.
بۆ ، کۆی دەبێت ڕاست بەرەو سەرەوە بێت و یەکسان بێت بە . : جاران ڕاکێشانی .
W is the weight in newtons (N); m is the mass in kilograms.
W واتە بە (N)؛ m واتە بە کیلۆگرام.
Weight: .
: .
Shared by four rotors: each.
بەسەر چوار : هەر یەکەیان .
Makers often give thrust in grams: 2.9 N can hold up about 300 g. So each motor gives about 300 g in a hover, half of the 600 g it can give at full power (Matching the parts).
دروستکەران زۆرجار بە گرام دەدەن: 2.9 N دەتوانێت نزیکەی 300 g هەڵبگرێت. کەواتە لە کاتی هەر نزیکەی 300 g دەدات، واتە نیوەی ئەو 600 gـەی بە تەواو دەتوانێت بیدات (گونجاندنی بەشەکان).
Torque: why neighbours spin opposite waysزەبر: بۆچی ڕۆتۆرەکانی دراوسێ بە پێچەوانەی یەک دەسووڕێنەوە
A turning : how strongly a force makes something rotate around an axis. It is the force times its distance from the axis; a spinning also twists its motor and the drone the other way.
سووڕێنەرە: ئەوەیە کە هێزێک بە چ بەهێزییەک شتێک بە دەوری تەوەرێکدا دەسووڕێنێت. یەکسانە بە هێزەکە جاران دووریی لە تەوەرەکە؛ سووڕاو ماتۆڕەکەی و بە ئاڕاستەی پێچەوانە با دەدات.
A motor turns its propeller one way, and the air resists the spinning blades. So the motor is twisted back the other way, and it twists the whole drone with it: that twist is torque. If all four propellers spun clockwise, the drone would slowly spin counter-clockwise, round and round.
بە ئاڕاستەیەک دەسووڕێنێت و هەوا بەرهەڵستیی پەڕە سووڕاوەکان دەکات. بۆیە بە ئاڕاستەکەی تر با دەدرێتەوە و هەموو لەگەڵ خۆیدا با دەدات: ئەو بادانە . ئەگەر هەر چوار بسووڕانەوە، بە هێواشی دەسووڕایەوە، بە بەردەوامی.
So a quadcopter has two clockwise and two counter-clockwise rotors. Rotors at opposite corners spin the same way and neighbours spin opposite ways. At equal speeds the four twists cancel and the nose stays still. A helicopter solves the same problem with its small tail rotor (Single-rotor helicopters).
بۆیە دوو و دوو هەیە. گۆشە بەرامبەرەکان بە یەک ئاڕاستە دەسووڕێنەوە و دراوسێکان بە پێچەوانەی یەک. کاتێک خێراییەکانیان یەکسان بێت، چوار بادانەکە یەکتر بەتاڵ دەکەنەوە و لووتی جێگیر دەمێنێتەوە. هەلیکۆپتەر هەمان کێشە بە بچووکی کلکی چارەسەر دەکات (هەلیکۆپتەرە بێفڕۆکەوانەکان).
Twist the lid of a tight jar of pickles with one hand and the jar tries to turn the other way, so your other hand must hold it still. A quadcopter has no "other hand": the rotors that spin the opposite way hold the body still.
سەرقاپی شیشەیەکی ترشی کە توند داخراوە بە دەستێک بسووڕێنە، شیشەکە هەوڵ دەدات بە ئاڕاستەکەی تر بسووڕێتەوە، بۆیە دەستەکەی ترت دەبێت ڕایبگرێت. «دەستێکی تری» نییە: ئەو بە پێچەوانەوە دەسووڕێنەوە لاشەکە ڕادەگرن.
Where the analogy stops workingسنووری ئەم نموونەیە
A hand grips the jar. The drone stays still only while both rotor pairs match; unbalance them and the body turns: that is yaw.
دەست شیشەکە دەگرێت. تەنیا کاتێک جێگیر دەمێنێتەوە کە هەردوو جووتە وەک یەک بن؛ هاوسەنگییەکەیان تێک بدە و لاشەکە دەسووڕێتەوە: ئەمە .
Up and down: throttleسەرکەوتن و دابەزین: گاز
The control that sets how much power goes to all the motors together. On a more throttle means more from every rotor, so the drone climbs; less throttle brings it down.
ئەو کۆنترۆڵەیە کە دیاری دەکات چەند هێز پێکەوە بدرێت بە هەموو ماتۆڕەکان. لە گازی زیاتر واتە زیاتر لە هەموو ، بۆیە بەرز دەبێتەوە؛ گازی کەمتر نزمی دەکاتەوە.
Vertical movement comes from changing all four rotors together. More throttle: all four spin faster, the thrust becomes bigger than the weight and the drone climbs. Less throttle: all four slow down, the thrust becomes smaller than the weight and the drone sinks. Thrust equal to weight: it hovers.
جووڵەی سەرەوە و خوارەوە لە گۆڕینی هەر چوار پێکەوە دێت. زیاتر: هەر چواریان خێراتر دەسووڕێنەوە، لە گەورەتر دەبێت و بەرز دەبێتەوە. کەمتر: هەر چواریان هێواش دەبنەوە، لە بچووکتر دەبێت و نزم دەبێتەوە. یەکسان بە : لە هەوادا ڕادەوەستێت.
Because both spin pairs change by the same amount, their twists stay balanced and the drone does not turn while it climbs. To come down gently, the drone needs a little less thrust than its weight, never zero: a drone with stopped motors falls like a stone.
چونکە هەردوو جووتەکە بە هەمان ئەندازە دەگۆڕێن، بادانەکانیان هاوسەنگ دەمێننەوە و لە کاتی بەرزبوونەوەدا ناسووڕێتەوە. بۆ ئەوەی بە نەرمی دابەزێت، پێویستی بە کەمێک کەمتر لە هەیە، هەرگیز سفر نا: کە وەستابن وەک بەرد دەکەوێتە خوارەوە.
Pitch and roll: tilting to moveلێژی و لاربوونەوە: لاربوون بۆ جووڵە
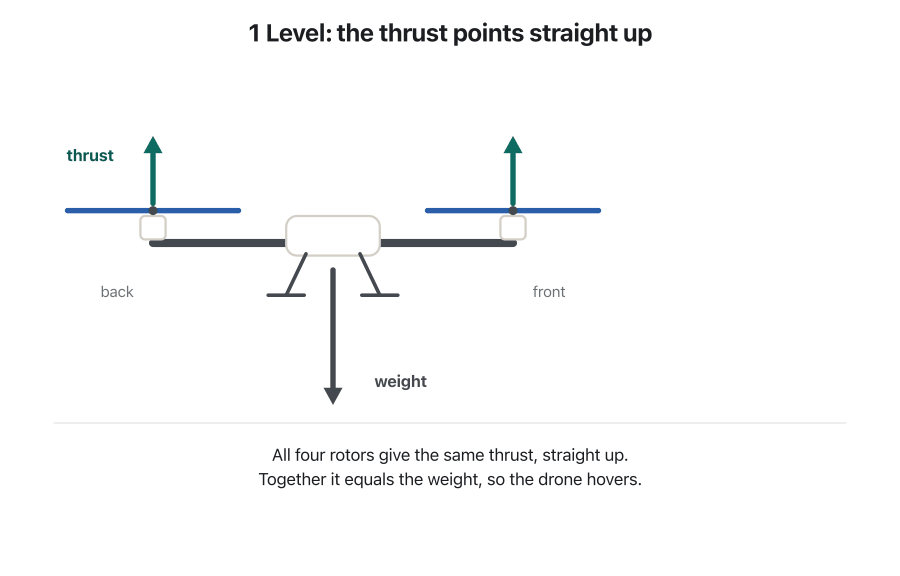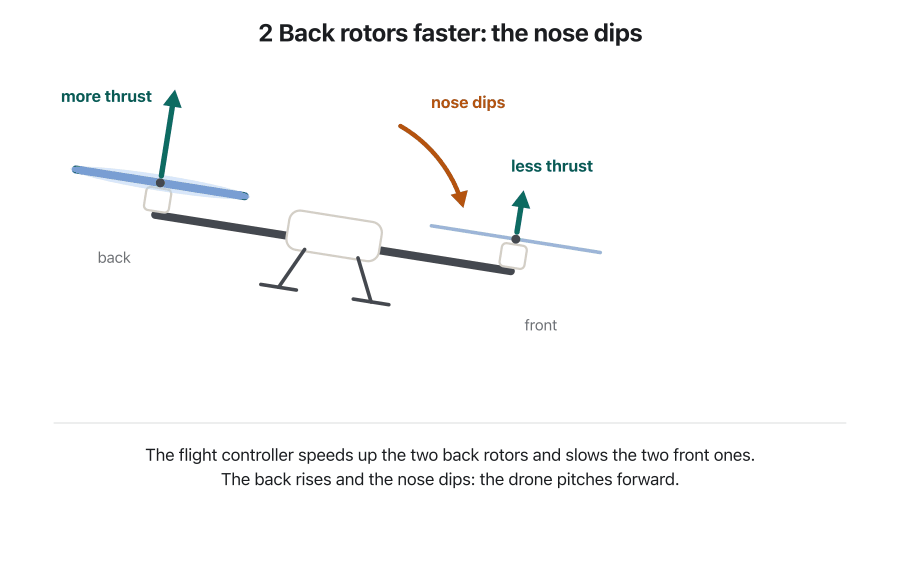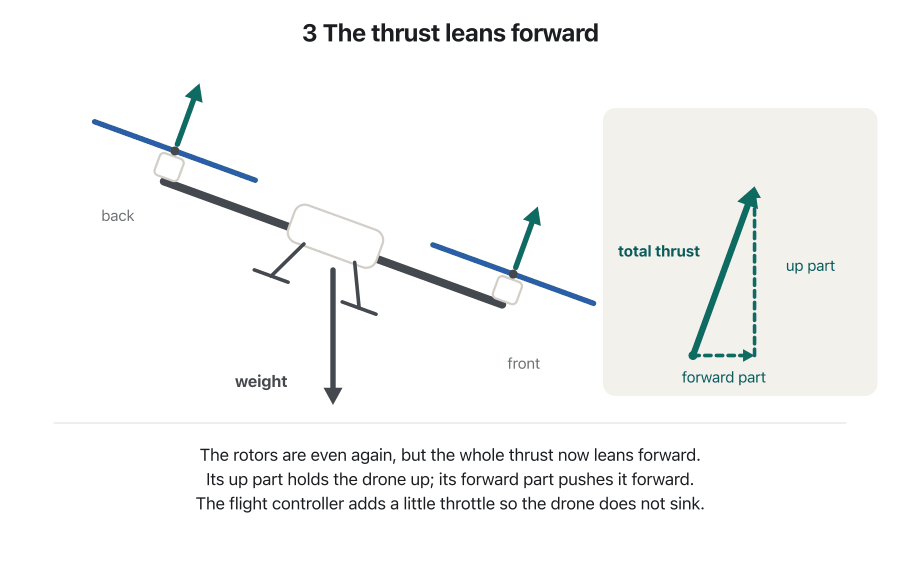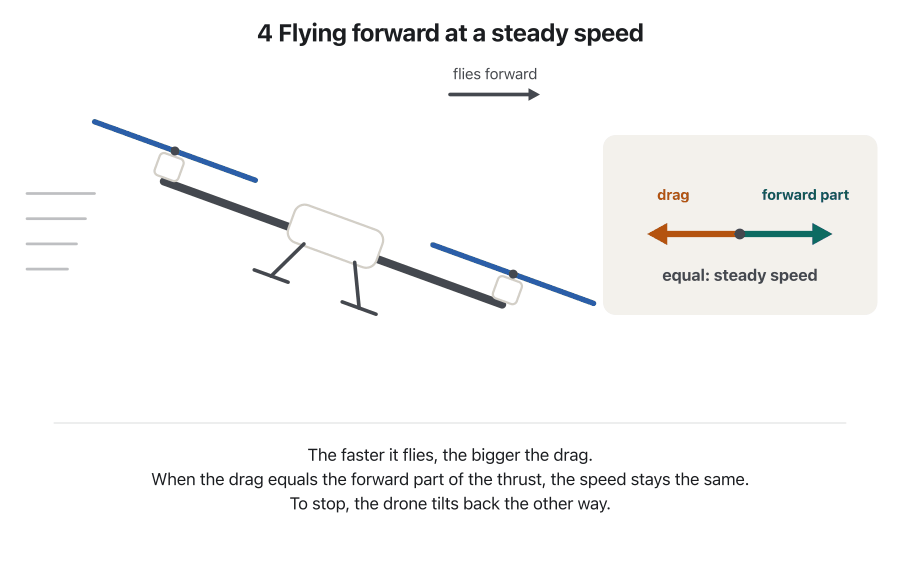
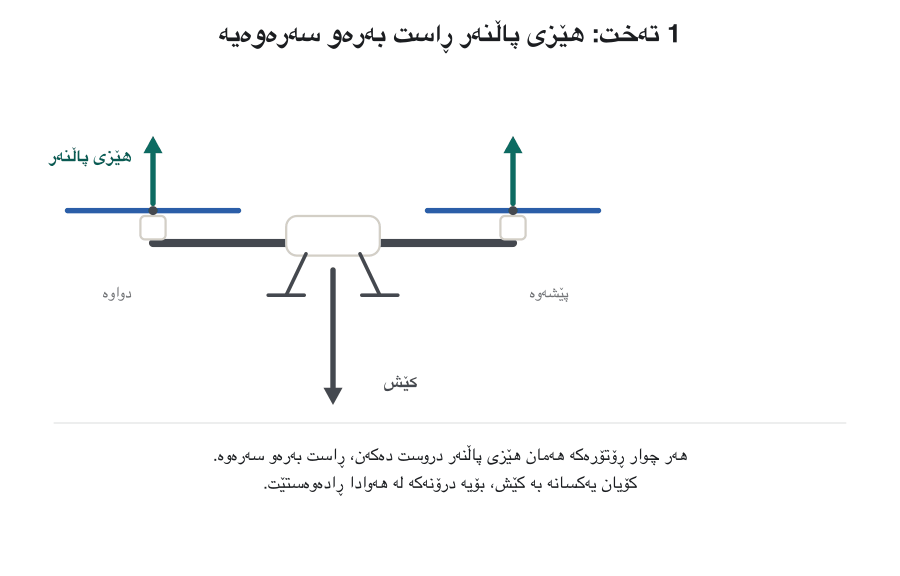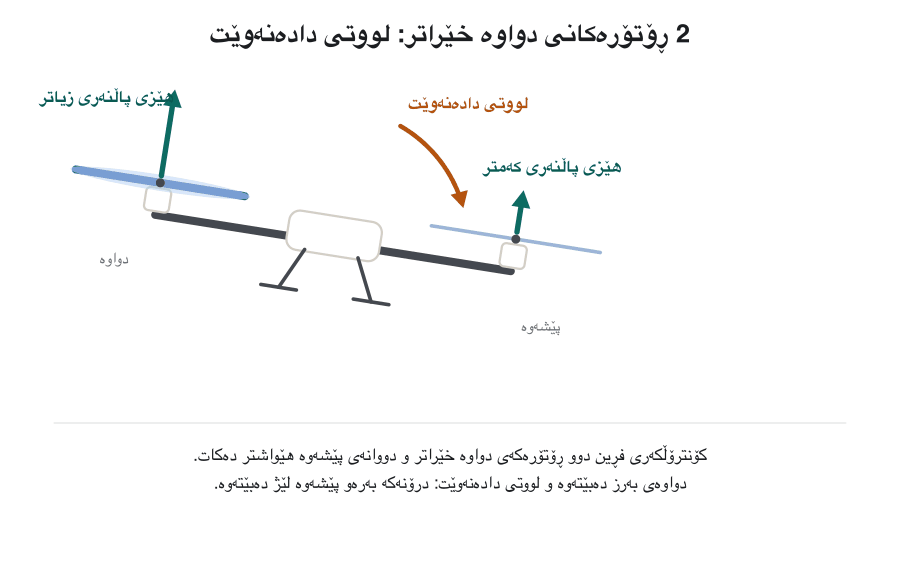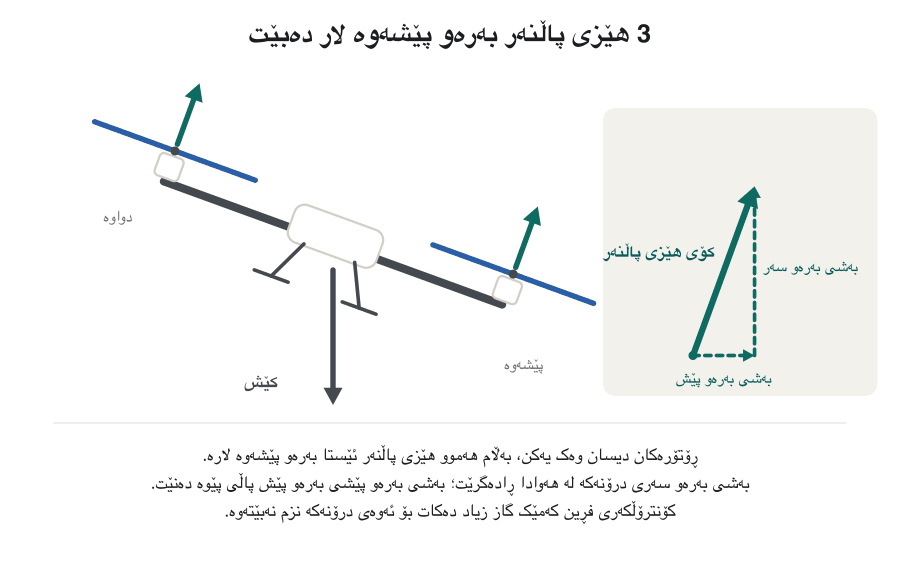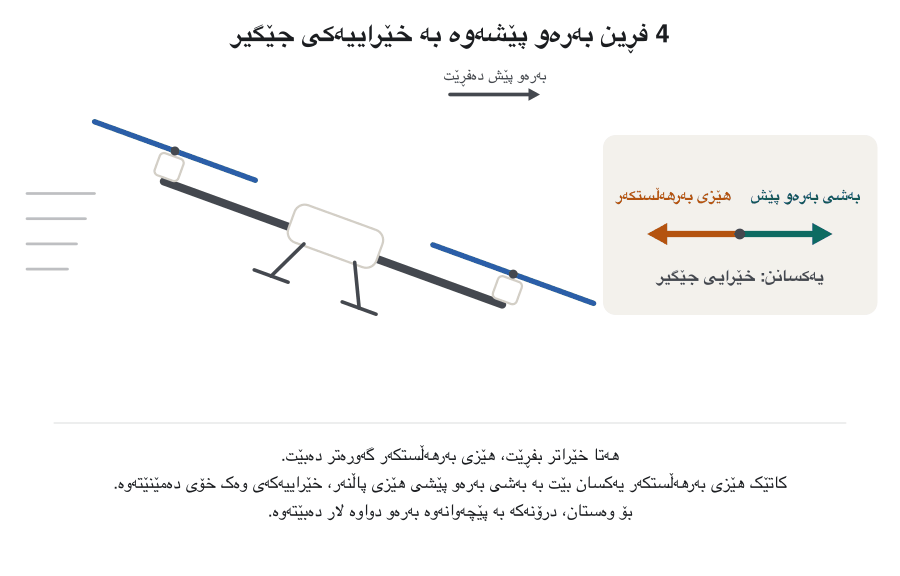
Quadcopters, the most common layout for small civil drones, steer and move by changing the speeds of different rotors. To move forward, back or sideways, a quadcopter tilts. Pitch means tilting the nose down or up; think of it as the drone's slope. To pitch forward, the flight controller speeds up the two back rotors and slows the two front ones: the back rises and the nose dips.
، کە باوترین شێوەن بۆ مەدەنیی بچووک، بە گۆڕینی خێرایی جیاواز ئاڕاستە وەردەگرن و دەجووڵێن. بۆ جووڵە بەرەو پێش، بەرەو دواوە یان بەرەو لا، لار دەبێتەوە. واتە نزمبوونەوە یان بەرزبوونەوەی لووت. بۆ بەرەو پێش، دوو دواوە خێراتر و دووانەکەی پێشەوە هێواشتر دەکات: دواوە بەرز دەبێتەوە و لووت دادەنەوێت.
Now the thrust leans forward. Part of it still holds the drone up; the other part pushes it forward. The up part is now a little smaller, so the flight controller adds a little throttle to stop the drone from sinking. As the speed grows, drag grows too; when the drag equals the forward push, the drone flies at a steady speed.
ئێستا بەرەو پێش لار دەبێتەوە. بەشێکی هێشتا بە بەرزی ڕادەگرێت؛ بەشەکەی تر بەرەو پێش پاڵی پێوە دەنێت. بەشە بەرەو سەرەکە ئێستا کەمێک بچووکترە، بۆیە کەمێک زیاد دەکات بۆ ئەوەی نزم نەبێتەوە. هەتا خێرایی زیاد بێت، زیاد دەبێت؛ کاتێک یەکسان بێت بە پاڵە بەرەو پێشەکە، بە خێراییەکی جێگیر دەفڕێت.
Pitch and roll: tilting to moveلێژی و لاربوونەوە: لاربوون بۆ جووڵە
Roll: tilting to the sideلاربوونەوە: بەلای چەپ یان ڕاستدا
Roll works the same way to the side. Speed up the two left rotors and slow the right ones: the right side dips and the drone slides to the right. Each side pair has one clockwise and one counter-clockwise rotor, so the twists stay balanced and the nose keeps pointing the same way.
بە هەمان شێوە بەرەو لا کار دەکات. دوو لای چەپ خێراتر و ئەوانەی لای ڕاست هێواشتر بکە: لای ڕاست نزم دەبێتەوە و بەرەو ڕاست دەخزێت. هەر جووتێکی لاوەکی یەک و یەکی هەیە، بۆیە بادانەکان هاوسەنگ دەمێننەوە و لووت بەرەو هەمان ئاڕاستە دەمێنێتەوە.
Yaw: turning on the spotسووڕانەوەی ئاسۆیی: سووڕانەوە لە شوێنی خۆیدا
Yaw turns the nose left or right while the drone stays level. It uses torque instead of tilt. Speed up one diagonal pair of rotors and slow the other pair by the same amount: the total thrust stays the same, so the height holds, but the twists no longer cancel. The body turns the opposite way to the spin of the faster pair.
لووت بەلای چەپ یان ڕاستدا دەسووڕێنێتەوە لە کاتێکدا تەخت دەمێنێتەوە. لە جیاتی لاربوون بەکار دەهێنێت. جووتێکی لاری خێراتر بکە و جووتەکەی تر بە هەمان ئەندازە هێواشتر: کۆی وەک خۆی دەمێنێتەوە، بۆیە ناگۆڕێت، بەڵام بادانەکان چیتر یەکتر بەتاڵ ناکەنەوە. لاشەکە بە پێچەوانەی ئاڕاستەی سووڕانەوەی جووتە خێراترەکە دەسووڕێتەوە.
On the usual X layout, the front-right and back-left rotors spin counter-clockwise. Speed them up and slow the clockwise pair, and the body turns clockwise seen from above: the nose swings to the right. That is yaw right.
لە شێوەی باوی Xـدا پێشەوەی ڕاست و دواوەی چەپ دەسووڕێنەوە. ئەوان خێراتر بکە و جووتە هێواشتر بکە، لاشەکە لە سەرەوە سەیر بکەیت دەسووڕێتەوە: لووت بەرەو ڕاست دەچێت. ئەمە بەلای ڕاستدایە.
Turning an aircraft's nose to the left or right while it stays level, around the up-down axis. A yaws by speeding up one diagonal pair of and slowing the other pair: the total thrust stays the same, but the no longer balance.
سووڕاندنەوەی لووتی فڕۆکەیە بەلای چەپ یان ڕاستدا لە کاتێکدا ڕێک دەمێنێتەوە، بە دەوری تەوەرە ستوونییەکەدا. بە خێراکردنی جووتێکی لاری و هێواشکردنی جووتەکەی تر دەسووڕێتەوە: کۆی وەک خۆی دەمێنێتەوە، بەڵام چیتر هاوسەنگ نین.
All the moves in one pictureهەموو جووڵەکان لە یەک وێنەدا
Watch the animation: a thicker, brighter rotor is spinning faster. Every move of a quadcopter is just a different pattern of four rotor speeds.
سەیری وێنە جووڵاوەکە بکە: ئەستوورتر و ڕووناکتر خێراتر دەسووڕێتەوە. هەموو جووڵەیەکی تەنیا شێوەیەکی جیاوازی خێرایی چوار .
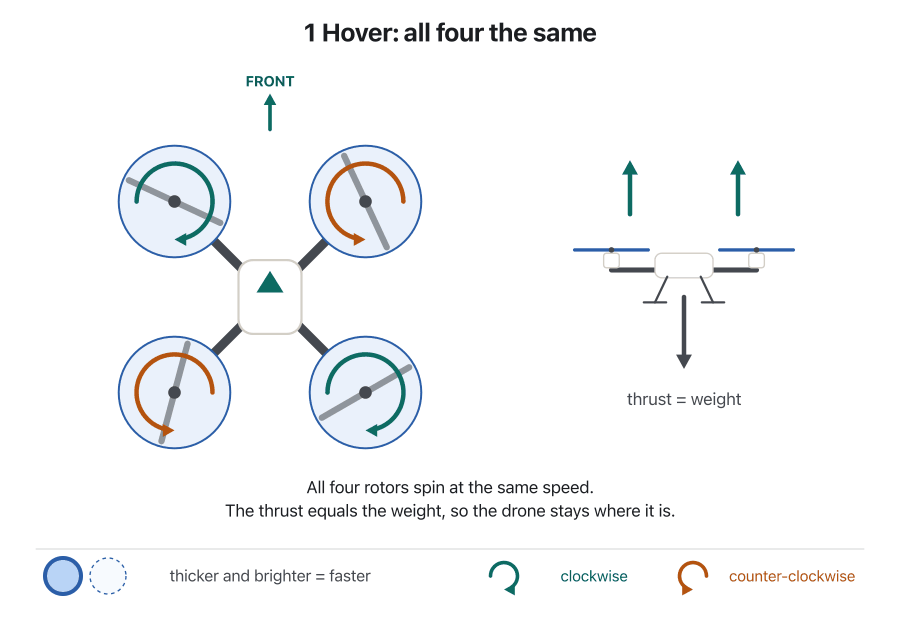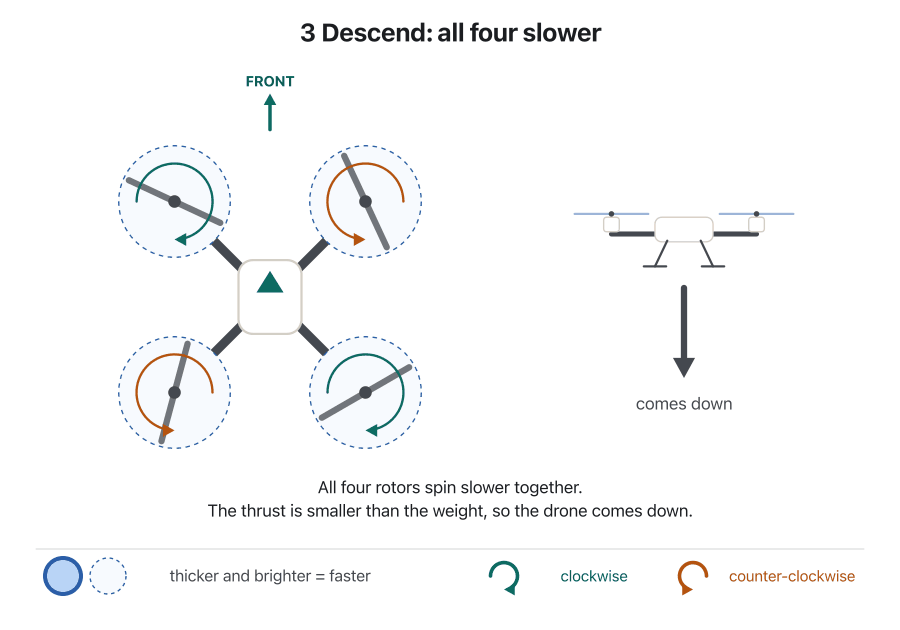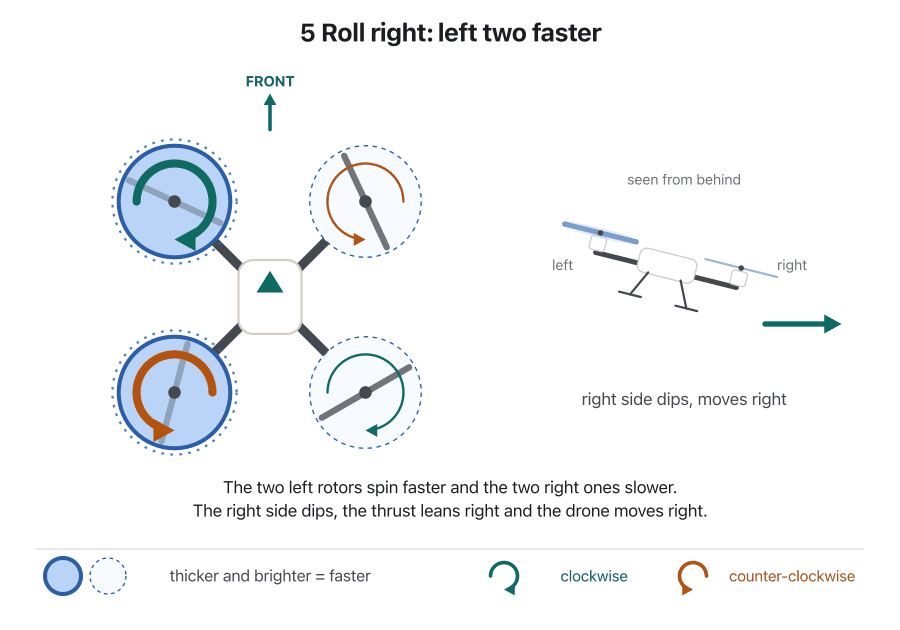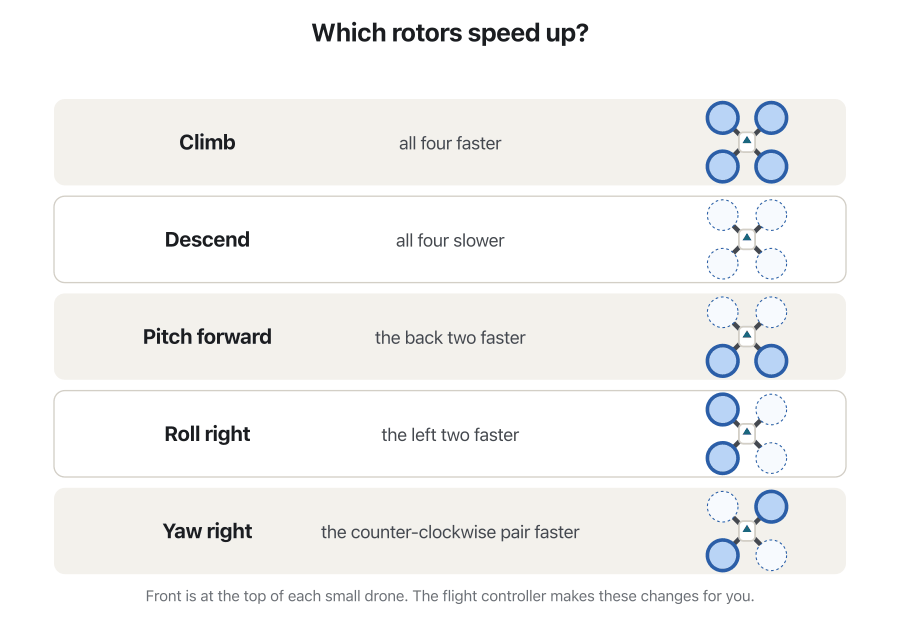
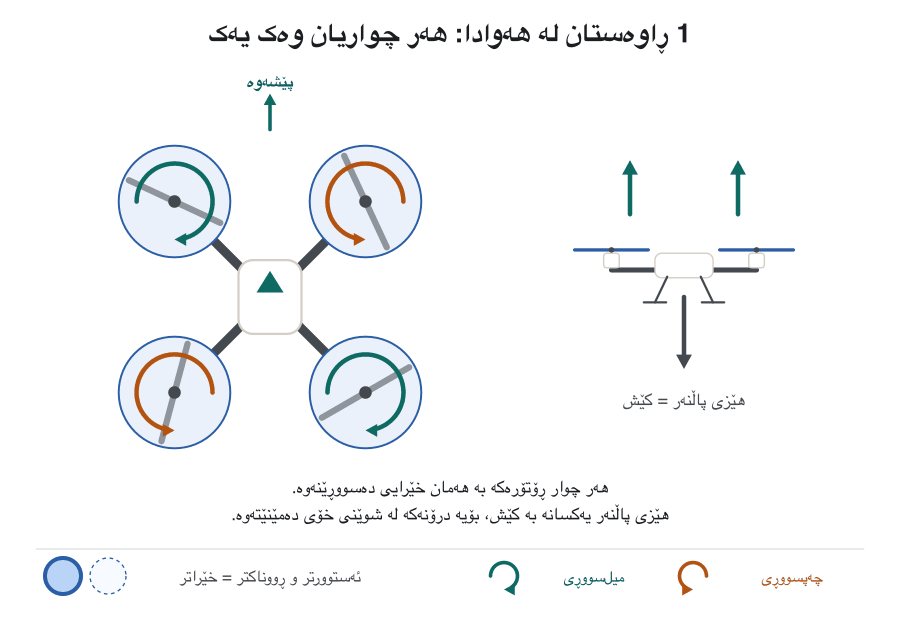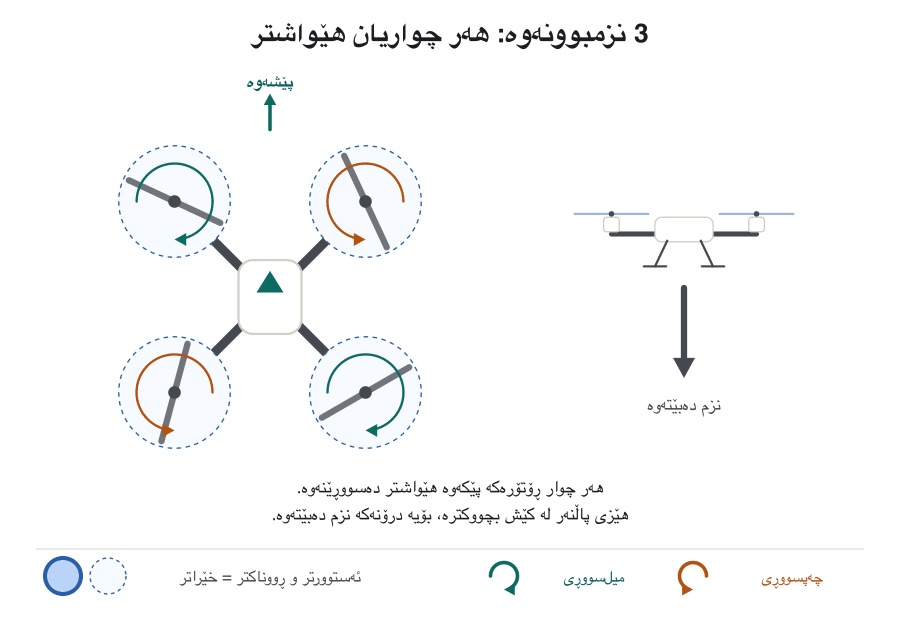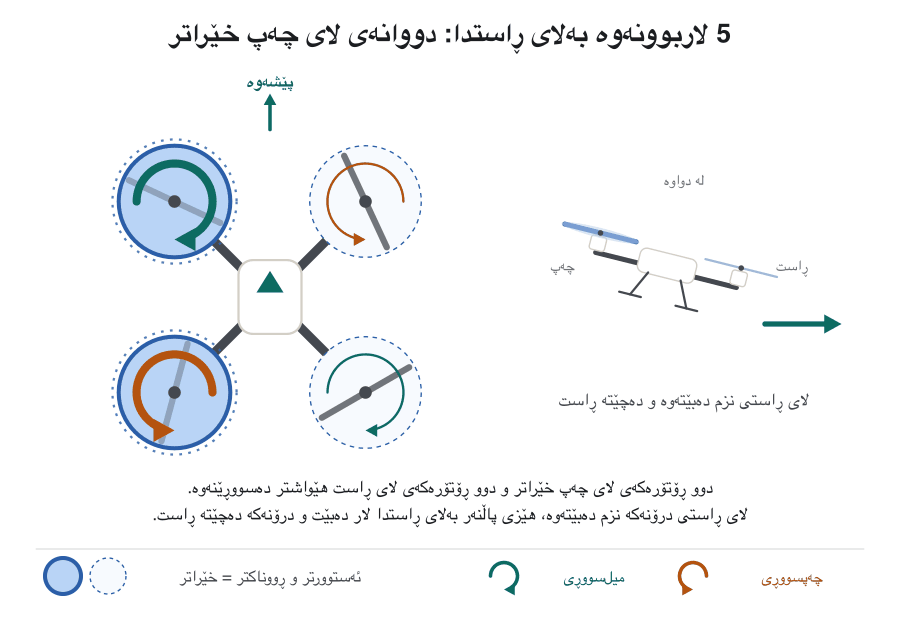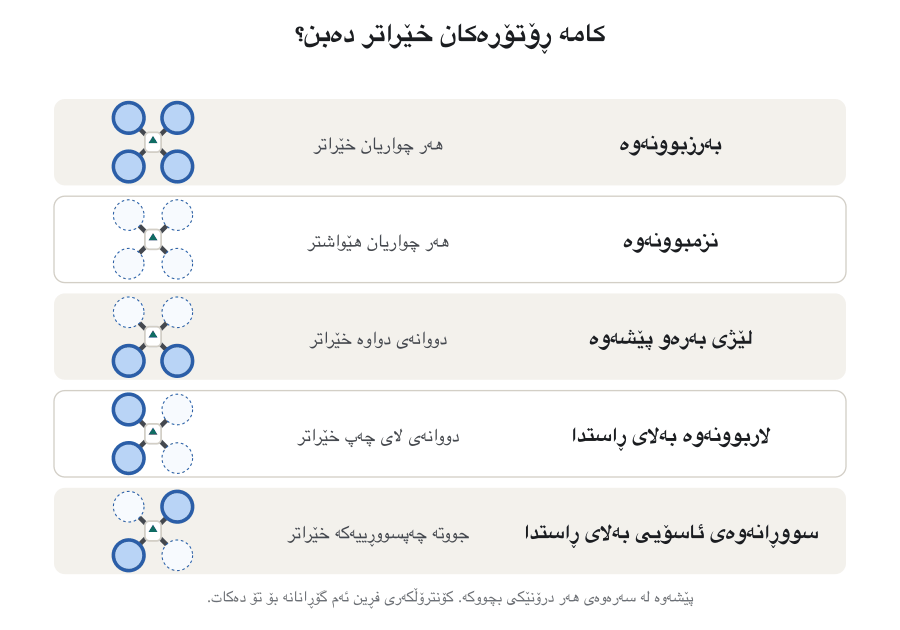
You never set these four speeds yourself. You move the sticks; the flight controller mixes your command into four motor speeds and corrects them hundreds of times a second (Loops inside loops).
تۆ هەرگیز خۆت ئەم چوار خێراییە دیاری ناکەیت. تۆ دەسکەکان دەجووڵێنیت؛ فەرمانەکەت دەکاتە چوار خێرایی و لە چرکەیەکدا سەدان جار ڕاستیان دەکاتەوە (خول لە ناو خولدا).
Three axes and two sticksسێ تەوەرە و دوو دەسک
Each turning move happens around an axis, an imaginary line through the middle of the drone: roll around the nose-to-tail axis, pitch around the side-to-side axis, and yaw around the up-and-down axis.
هەر جووڵەیەکی سووڕانەوە بە دەوری ڕوو دەدات، کە هێڵێکی خەیاڵییە بە ناوەڕاستی : بە دەوری نێوان لووت و کلک، بە دەوری نێوان چەپ و ڕاست و بە دەوری نێوان سەرەوە و خوارەوە.
A remote controller in Mode 2, the most common setup, puts throttle and yaw on the left stick and pitch and roll on the right stick: right stick up flies forward, right stick right slides right, left stick up climbs and left stick right turns the nose right. Mode 1 swaps throttle and pitch between the sticks, so always check which mode your controller uses.
بە شێوەی Mode 2، کە باوترین ڕێکخستنە، و دەخاتە سەر دەسکی چەپ و و دەخاتە سەر دەسکی ڕاست: دەسکی ڕاست بۆ سەرەوە: بەرەو پێش دەفڕێت؛ دەسکی ڕاست بۆ لای ڕاست: بەرەو ڕاست دەخزێت؛ دەسکی چەپ بۆ سەرەوە: بەرز دەبێتەوە؛ دەسکی چەپ بۆ لای ڕاست: لووتی بەرەو ڕاست دەسووڕێتەوە. Mode 1 شوێنی و لە نێوان دەسکەکاندا دەگۆڕێتەوە، بۆیە هەمیشە بپشکنە کام شێوە بەکار دەهێنێت.
Thin air, hot days and windهەوای تەنک، ڕۆژی گەرم و با
A propeller can only push the air that is there. High up and on hot days the air is thinner: its air density is lower. At the same rotor speed the thrust is then smaller, roughly in proportion to the density. The motors must spin faster, use more battery and keep less spare thrust.
تەنیا دەتوانێت ئەو هەوایە پاڵ بنێت کە هەیە. لە بەرزی و لە ڕۆژی گەرمدا هەوا تەنکترە: کەمترە. ئەو کاتە بە هەمان خێرایی ، بچووکترە، نزیکەی بە ڕێژەی چڕییەکە. دەبێت خێراتر بسووڕێنەوە، زیاتر بەکار بهێنن و زیادەی کەمتریان بۆ بمێنێتەوە.
Wind costs thrust too. To stay in one place in a steady wind, the drone must tilt into the wind, just as if it were flying forward. Gusts need spare thrust for quick corrections. Flying back against the wind with a low battery is a classic way to lose a drone, so check the forecast and the drone's wind limit before you fly (Flying safely).
با هەروەها دەخوات. بۆ ئەوەی لە بایەکی بەردەوامدا لە یەک شوێندا بمێنێتەوە، دەبێت بەرەو با لار ببێتەوە، هەر وەک ئەوەی بەرەو پێش بفڕێت. بای کتوپڕ زیادەی بۆ ڕاستکردنەوەی خێرا پێویستە. گەڕانەوە بە پێچەوانەی با لە کاتێکدا کەمە ڕێگایەکی باوە بۆ لەدەستدانی ، بۆیە پێش فڕین پێشبینیی کەش و سنووری بای بپشکنە (فڕینی سەلامەت).
Common mistakesهەڵە باوەکان
| Mistakeهەڵە | Fixچارەسەر |
|---|---|
| Explaining lift with the "equal transit time" story.ڕوونکردنەوەی بە چیرۆکی «کاتی تێپەڕینی یەکسان». | Lift and thrust come from turning the air, with the pressure difference that goes with it. و لە لادانی هەواوە دێن، لەگەڵ ئەو جیاوازییەی پەستان کە لەگەڵیدا دێت. |
| All four rotors spin the same way.هەر چوار بە یەک ئاڕاستە دەسووڕێنەوە. | Two spin clockwise and two counter-clockwise; opposite corners match.دوویان و دوویان دەسووڕێنەوە؛ گۆشە بەرامبەرەکان وەک یەکن. |
| To fly forward, the front rotors speed up.بۆ فڕین بەرەو پێش، پێشەوە خێرا دەبن. | The back rotors speed up, the nose dips and the thrust leans forward. دواوە خێرا دەبن، لووت دادەنەوێت و بەرەو پێش لار دەبێت. |
| Yaw means tilting the drone. واتە لارکردنەوەی . | Yaw turns the nose while the drone stays level; it comes from unbalancing the torque of the two pairs. لووت دەسووڕێنێتەوە لە کاتێکدا تەخت دەمێنێتەوە؛ لە لەناوبردنی هاوسەنگیی دوو جووتەکەوە دێت. |
| Weight is measured in kilograms. بە کیلۆگرام دەپێورێت. | Mass is in kilograms; weight is a force in newtons: . بە کیلۆگرامە؛ بە : . |
| A hovering drone needs hardly any power. کە لە هەوادا ڕاوەستاوە بە زەحمەت پێویستی بە وزە هەیە. | Hovering needs thrust equal to the whole weight all the time, so it uses a lot of battery. هەموو کاتێک یەکسان بە هەموو پێویستە، بۆیە زۆر بەکار دەهێنێت. |
| Thrust is the same everywhere. لە هەموو شوێنێک وەک یەکە. | Thin, hot or high air gives less thrust at the same rotor speed.هەوای تەنک، گەرم یان بەرز بە هەمان خێرایی کەمتر دەدات. |
Exercisesڕاهێنانەکان
Copy the table and fill it in for a quadcopter with the usual X layout: for each move, which rotors speed up and which slow down? Use FL (front-left), FR (front-right), BL (back-left) and BR (back-right). FR and BL spin counter-clockwise.
خشتەکە بنووسەوە و بۆ بە شێوەی باوی X پڕی بکەرەوە: بۆ هەر جووڵەیەک کام خێرا دەبن و کامیان هێواش؟ FL (پێشەوەی چەپ)، FR (پێشەوەی ڕاست)، BL (دواوەی چەپ) و BR (دواوەی ڕاست) بەکار بهێنە. FR و BL دەسووڕێنەوە.
Show answerوەڵامەکە پیشان بدە
| Moveجووڵە | Fasterخێراتر | Slowerهێواشتر |
|---|---|---|
| Climbبەرزبوونەوە | FL, FR, BL, BRFL، FR، BL، BR | noneهیچ |
| Descendنزمبوونەوە | noneهیچ | FL, FR, BL, BRFL، FR، BL، BR |
| Pitch forward بەرەو پێش | BL, BRBL، BR | FL, FRFL، FR |
| Pitch back بەرەو دواوە | FL, FRFL، FR | BL, BRBL، BR |
| Roll right بەلای ڕاستدا | FL, BLFL، BL | FR, BRFR، BR |
| Roll left بەلای چەپدا | FR, BRFR، BR | FL, BLFL، BL |
| Yaw right بەلای ڕاستدا | FR, BL (counter-clockwise pair)FR، BL (جووتە ) | FL, BRFL، BR |
| Yaw left بەلای چەپدا | FL, BR (clockwise pair)FL، BR (جووتە ) | FR, BLFR، BL |
A 2.0 kg hexacopter (six rotors) hovers. Find its weight and the thrust each rotor must give.
2.0 کیلۆیی (شەش ) لە هەوادا ڕاوەستاوە. و ئەو هەر دەبێت بیدات بدۆزەرەوە.
Show answerوەڵامەکە پیشان بدە
Each of the six rotors gives about 3.3 N, the weight of about 333 g.
هەر یەکێک لە شەش نزیکەی 3.3 N دەدات، واتە بەس بۆ هەڵگرتنی نزیکەی 333 g.
In two or three sentences, explain why a quadcopter with four clockwise propellers would spin, and how real quadcopters prevent it.
بە دوو یان سێ ڕستە ڕوونی بکەرەوە بۆچی بە چوار دەسووڕێتەوە و ڕاستەقینە چۆن ڕێگری لێ دەکەن.
Show answerوەڵامەکە پیشان بدە
Each spinning propeller twists its motor, and the whole drone, the opposite way (torque). With four clockwise propellers all four twists point the same way, so the body spins counter-clockwise. Real quadcopters use two clockwise and two counter-clockwise rotors on opposite corners, so the twists cancel.
هەر سووڕاو و هەموو بە ئاڕاستەی پێچەوانە با دەدات (). بە چوار ، هەر چوار بادانەکە بە یەک ئاڕاستەن، بۆیە لاشەکە دەسووڕێتەوە. ڕاستەقینە دوو و دوو لە گۆشە بەرامبەرەکاندا بەکار دەهێنن، بۆیە بادانەکان یەکتر بەتاڵ دەکەنەوە.
A drone needs 11.8 N of thrust to hover. At 2,000 m the air is about 18 % less dense. If the rotors keep their sea-level speed, about how much thrust do they make? What must the flight controller do?
بۆ پێویستی بە 11.8 N هەیە. لە 2,000 mـدا نزیکەی 18 % کەمترە. ئەگەر خێرایی ئاستی دەریایان بپارێزن، نزیکەی چەند دروست دەکەن؟ دەبێت چی بکات؟
Show answerوەڵامەکە پیشان بدە
About 9.7 N, less than the weight, so the drone would sink. The flight controller adds throttle: the rotors spin faster until the thrust is 11.8 N again.
نزیکەی 9.7 N، کەمتر لە ، بۆیە نزم دەبێتەوە. زیاد دەکات: خێراتر دەسووڕێنەوە هەتا دیسان دەبێتە 11.8 N.
With a Mode 2 controller, which stick moves would you make to: (1) take off and climb, (2) fly forward, (3) turn the nose to the left?
بە بە شێوەی Mode 2، چ جووڵەیەکی دەسک دەکەیت بۆ: (1) هەڵفڕین و بەرزبوونەوە، (2) فڕین بەرەو پێش، (3) سووڕاندنی لووت بەلای چەپدا؟
Show answerوەڵامەکە پیشان بدە
- (1) Left stick up (throttle).
- (2) Right stick up (pitch forward).
- (3) Left stick to the left (yaw left).
- (1) دەسکی چەپ بۆ سەرەوە ().
- (2) دەسکی ڕاست بۆ سەرەوە ( بەرەو پێش).
- (3) دەسکی چەپ بەرەو چەپ ( بەلای چەپدا).
Summaryپوختە
- Aerodynamic shapes move through the air easily, are slowed less and save energy.
- Four forces: weight down, lift up, thrust along, drag back. On a multirotor the rotors' thrust does the job of lift.
- A propeller makes thrust by turning air downwards (Newton's third law, lower pressure above); the "equal transit time" story is wrong.
- To hover, thrust = weight: ; a 1.2 kg drone needs about 2.9 N per rotor.
- Diagonal rotors spin the same way, so the torques cancel. Throttle: all four together. Pitch and roll: speed up one side to tilt. Yaw: speed up one diagonal pair.
- Mode 2: left stick = throttle and yaw, right stick = pitch and roll. Thin, hot air and wind reduce spare thrust.
- شێوەی بە ئاسانی بە ناو هەوادا دەجووڵێت، کەمتر هێواش دەبێتەوە و وزە دەپارێزێت.
- چوار : بەرەو خوارەوە، بەرەو سەرەوە، بەرەو پێش، بەرەو دواوە. لە کاری دەکات.
- بە لادانی هەوا بەرەو خوارەوە دروست دەکات (، کەمتر لە سەرەوە)؛ چیرۆکی «کاتی تێپەڕینی یەکسان» هەڵەیە.
- بۆ ، = : ؛ 1.2 کیلۆیی بۆ هەر نزیکەی 2.9 Nـی پێویستە.
- لار بە یەک ئاڕاستە دەسووڕێنەوە، بۆیە یەکتر بەتاڵ دەکەنەوە. : هەر چواریان پێکەوە. و : لایەک خێراتر بکە بۆ لاربوون. : جووتێکی لار خێراتر بکە.
- Mode 2: دەسکی چەپ = و ، دەسکی ڕاست = و . هەوای تەنک و گەرم و با زیادە کەم دەکەنەوە.
Why does a quadcopter tilt to fly forward?بۆچی چوارپەروانە بۆ فڕین بەرەو پێش لار دەبێتەوە؟
Its thrust always points along the rotor shafts. Tilting leans the thrust forward, so part of it pushes the drone along while the rest holds it up.
هەمیشە بە درێژایی میلی . لاربوون بەرەو پێش لار دەکات، بۆیە بەشێکی بەرەو پێش دەبات و باقییەکەی بە بەرزی ڕایدەگرێت.
How can a quadcopter turn without tilting?چوارپەروانە چۆن بەبێ لاربوون دەسووڕێتەوە؟
By yaw: one diagonal pair speeds up and the other slows down by the same amount. The total thrust stays the same, but the unbalanced torque turns the body.
بە : جووتێکی لار خێرا دەبێت و جووتەکەی تر بە هەمان ئەندازە هێواش. کۆی وەک خۆی دەمێنێتەوە، بەڵام ناهاوسەنگ لاشەکە دەسووڕێنێتەوە.
What is wrong with the "equal transit time" explanation?چی هەڵەیە لە ڕوونکردنەوەی «کاتی تێپەڕینی یەکسان»؟
Nothing forces the air above and below to meet at the back; in fact the air over the top arrives earlier. Lift comes from turning the air (with lower pressure above).
هیچ شتێک هەوای سەرەوە و خوارەوە ناچار ناکات لە دواوە بگەنەوە یەک؛ لە ڕاستیدا هەوای سەرەوە زووتر دەگات. لە لادانی هەواوە دێت (لەگەڵ کەمتر لە سەرەوە).
Why does a drone need more power in the mountains?بۆچی درۆن لە شاخدا پێویستی بە وزەی زیاترە؟
The air is thinner, so each turn of the propeller pushes less air and makes less thrust; the motors must spin faster.
هەوا تەنکترە، بۆیە هەر سووڕانەوەیەکی هەوای کەمتر پاڵ دەنێت و کەمتر دروست دەکات؛ دەبێت خێراتر بسووڕێنەوە.
Lesson complete!وانەکە تەواو بوو!
Well done. Review the key terms, then go on to the next lesson.دەستخۆش. سەیرێکی زاراوە سەرەکییەکان بکەرەوە، پاشان بڕۆ بۆ وانەی داهاتوو.
Key termsزاراوە سەرەکییەکان
The Flight Controller: Sensors, Control Loops and Autopilotsکۆنترۆڵکەری فڕین: هەستەوەرەکان، خولەکانی کۆنترۆڵ و فڕۆکەوانی خۆکار
Related lecturesوانە پەیوەندیدارەکان
- Types of Drones: Multirotors, Fixed Wings, Helicopters and VTOLجۆرەکانی درۆن: فرەپەروانە، درۆنی باڵجێگیر، هەلیکۆپتەری بێفڕۆکەوان و VTOL
- The Flight Controller: Sensors, Control Loops and Autopilotsکۆنترۆڵکەری فڕین: هەستەوەرەکان، خولەکانی کۆنترۆڵ و فڕۆکەوانی خۆکار
- Flying Safely: VLOS, EVLOS, BVLOS, Weather and Pre-flight Checksفڕینی سەلامەت: هێڵی بینینی چاو، هێڵی بینینی درێژکراوە، دەرەوەی هێڵی بینین، کەشوهەوا و پشکنینی پێش فڕین
- Batteries and Power: LiPo Cells, Flight Time and Safetyپاتری و وزە: خانەکانی LiPo، کاتی فڕین و سەلامەتی
References and further readingسەرچاوەکان و خوێندنەوەی زیاتر
- NASA Glenn Research Center: Four Forces on an Airplane
- NASA Glenn Research Center: What is Lift?
- NASA Glenn Research Center: Incorrect Lift Theory #1 (longer path / equal transit time)
- NASA Glenn Research Center: Propeller Thrust
- NASA Glenn Research Center: Aircraft Rotations (roll, pitch and yaw axes)
- NASA Glenn Research Center: Earth Atmosphere Model (metric units)
- ArduPilot Copter: Connect ESCs and Motors (Quad X motor order and spin directions)
- ArduPilot Copter: Radio Control Calibration (Mode 2 stick layout, channel mapping)
This lecture is a first edition. The Kurdish text and terminology are waiting for review by Kurdish IT teachers.ئەم وانەیە چاپی یەکەمە. دەقە کوردییەکە و زاراوەکانی چاوەڕێی پێداچوونەوەی مامۆستایانی کوردی بواری IT ن.