Chapterبەش 1 · Lectureوانە 1.2
Types of Drones: Multirotors, Fixed Wings, Helicopters and VTOLجۆرەکانی درۆن: فرەپەروانە، درۆنی باڵجێگیر، هەلیکۆپتەری بێفڕۆکەوان و VTOL
The four families of drones — multirotors (quad, hexa, octo), fixed wings, single-rotor helicopters and hybrid VTOL — how each one flies, what it is good and bad at, and how to choose the right one for a job.
چوار خێزانی — (چوار، شەش و هەشت )، ، و VTOLـی تێکەڵ — هەریەکەیان چۆن دەفڕێت، لە چیدا باشە و لە چیدا لاوازە، هەروەها چۆن جۆری گونجاو بۆ کارێک هەڵدەبژێریت.
What you will learnچی فێر دەبیت
- Name the four families of drones and recognise each one from a picture.
- Explain why neighbouring rotors of a multirotor spin in opposite directions, and draw the "+" and "X" quadcopter layouts.
- Explain what extra rotors give (lift, redundancy) and what they cost, and why stability comes from the flight controller.
- Describe how fixed wings, helicopters and hybrid VTOL drones take off, fly and land, with their strengths and weaknesses.
- Choose a suitable drone family for a job and justify the choice.
- چوار خێزانی ناو ببەیت و هەریەکەیان لە وێنەدا بناسیتەوە.
- ڕوونی بکەیتەوە بۆچی هەر دوو تەنیشت یەک لە بە پێچەوانەی یەک دەسووڕێنەوە و شێوەی «+» و «X»ی بکێشیت.
- ڕوونی بکەیتەوە زیادە چی دەدات (، ) و تێچووی چییە، هەروەها بۆچی جێگیری لە دێت.
- وەسف بکەیت ، هەلیکۆپتەر و تێکەڵەکانی چۆن هەڵدەفڕن، دەفڕن و دەنیشنەوە، لەگەڵ خاڵە بەهێز و لاوازەکانیان.
- خێزانێکی گونجاوی بۆ کارێک هەڵبژێریت و هۆکاری هەڵبژاردنەکە بڵێیت.
Four families of dronesچوار خێزانی درۆن
Drones are sorted into types by how they make the force that holds them up. There are four big families:
بەپێی ئەوەی چۆن ئەو هێزە دروست دەکەن کە لە هەوادا ڕایاندەگرێت بەسەر جۆرەکاندا دابەش دەکرێن. چوار خێزانی گەورە هەن:
- Multirotors have several spinning rotors (usually four, six or eight) that push air down. They can hover in one place.
- Fixed-wing drones look like small aeroplanes. Their wings hold them up while a propeller pulls or pushes them forward.
- Single-rotor helicopters have one big main rotor on top and a small rotor on the tail.
- Hybrid VTOL drones (vertical take-off and landing) take off straight up like a multirotor, then fly on wings like an aeroplane.
- چەند سووڕاویان هەیە (زۆرجار چوار، شەش یان هەشت) کە هەوا بەرەو خوارەوە دەپاڵن. دەتوانن لە یەک شوێندا لە هەوادا ڕاوەستن.
- لە فڕۆکەی بچووک دەچن. باڵەکانیان بە بەرزی ڕایاندەگرن و بەرەو پێشەوە ڕایاندەکێشێت یان پاڵیان پێوە دەنێت.
- سەرەکیی گەورەیان لە سەرەوە هەیە و بچووکیش لەسەر کلکیان.
- تێکەڵەکانی وەک ڕاست بەرەو سەرەوە هەڵدەفڕن و پاشان وەک فڕۆکە بە باڵ دەفڕن.
Each family is a trade-off: hovering costs a lot of energy, and long flights need wings.
هەر خێزانێک ئاڵوگۆڕێکە: وزەیەکی زۆر دەخوات و فڕینی درێژیش باڵی پێویستە.
Multirotors: the quadcopterفرەپەروانەکان: چوارپەروانە
The quadcopter (four rotors) is the most common drone for small civil jobs such as filming and inspection. It is mechanically simple — four motors with fixed propellers — and very manoeuvrable: it can hover, climb straight up, turn on the spot and move in any direction.
(چوار ) باوترین بۆ کارە مەدەنییە بچووکەکانی وەک وێنەگرتن و پشکنین. لە ڕووی میکانیکییەوە سادەیە — چوار بە جێگیرەوە — و زۆر بە ئاسانی دەجووڵێت: دەتوانێت لە هەوادا ڕاوەستێت، ڕاست بەرەو سەرەوە بەرز ببێتەوە، لە جێی خۆیدا بسووڕێتەوە و بەرەو هەر لایەک بڕوات.
Look at the spin arrows. Neighbouring rotors always spin in opposite directions: two clockwise (CW) and two counter-clockwise (CCW). Each spinning propeller twists the body the other way (torque); the opposite pairs cancel each other, so the drone does not spin like a top. To move, the flight controller changes the speed of single rotors — How a quadcopter flies explains how.
سەیری تیرەکانی سووڕانەوە بکە. هەر دوو تەنیشت یەک هەمیشە بە ئاراستەی پێچەوانە دەسووڕێنەوە: دوانیان و دوانیان (لە وێنەکەدا CW و CCW). هەر کە دەسووڕێت لەشەکە بە ئاراستەی پێچەوانە با دەدات ()؛ جووتە پێچەوانەکان یەکتر لادەبەن، بۆیە وەک فرفرە ناسووڕێتەوە. بۆ جووڵان، خێرایی یەکە یەکە دەگۆڕێت — چوارپەروانە چۆن دەفڕێت ڕوونی دەکاتەوە.
The arms can form a "+" layout (one arm points to the front) or an "X" layout (the front lies between two arms). X is more popular because a forward camera can look out between the arms.
باسکەکان دەتوانن شێوەی «+» پێک بهێنن (باسکێک بەرەو پێشەوەیە) یان شێوەی «X» (پێشەوە لە نێوان دوو باسکدایە). X باوترە، چونکە کامێرایەکی پێشەوە دەتوانێت لە نێوان باسکەکانەوە بڕوانێت.
Six or eight rotorsشەش یان هەشت ڕۆتۆر
A hexacopter has six rotors and an octocopter eight. More rotors give more lift, so the drone can carry heavier cameras, sensors or spray tanks, and redundancy: spare rotors that may keep it flying if one motor stops. But they also cost more, weigh more and use more energy, so a heavy octocopter usually flies for a shorter time than a light quadcopter.
شەش هەیە و هەشت. زیاتر زیاتر دەدات، بۆیە دەتوانێت کامێرا، یان تانکی ڕشاندنی قورستر هەڵبگرێت، هەروەها دەدات: یەدەگ کە لەوانەیە بە فڕین بهێڵێتەوە ئەگەر بوەستێت. بەڵام ئەم گرانترن، قورسترن و وزەی زیاتر بەکار دەهێنن، بۆیە قورس زۆرجار لە سووک ماوەیەکی کورتتر دەفڕێت.
Some frames put two rotors on one arm, one above the other, spinning in opposite directions (a coaxial pair). An X8 has four arms with eight rotors; a Y6 has three arms with six. This keeps the drone compact while giving it more rotors.
هەندێک چوارچێوە دوو لەسەر یەک باسک دادەنێن، یەکێکیان لە سەرووی ئەوی ترەوە و بە ئاراستەی پێچەوانە دەسووڕێنەوە (جووتێکی هاوتەوەر). X8 چوار باسک و هەشت هەیە؛ Y6 سێ باسک و شەش . بەم شێوەیە بچووک دەمێنێتەوە و زیاتری دەبێت.
Six or eight rotorsشەش یان هەشت ڕۆتۆر
When a motor stopsکاتێک ماتۆڕێک دەوەستێت
Imagine that one motor stops in the air. A quadcopter has no spare: it loses the balance of thrust and twist, and with ordinary flight software it falls. That one motor is a single point of failure. Researchers have kept quadcopters flying after losing a propeller by letting them spin fast like a top, but ordinary drones cannot do this.
وای دابنێ لە ئاسماندا بوەستێت. هیچ یەدەگێکی نییە: هاوسەنگیی و لەدەست دەدات و بە ئاسایی دەکەوێت. ئەو یەک . توێژەران توانیویانە دوای لەدەستدانی بە فڕین بهێڵنەوە، بەوەی وەک فرفرە بە خێرایی دەیسووڕێنن، بەڵام ئاساییەکان ناتوانن ئەمە بکەن.
A hexacopter or octocopter has a chance. Its flight controller can notice the dead motor and make the other rotors work harder. Research on a common hexacopter layout shows that it then cannot control all three ways of turning at once: it can keep itself level, but it may slowly spin around (yaw) as it comes down. With enough spare thrust and software made for this, that is enough to land safely.
یان هەلێکی هەیە. دەتوانێت هەست بە وەستاوەکە بکات و تر زیاتر کار پێ بکات. توێژینەوەیەک لەسەر شێوەیەکی باوی پیشانی داوە کە ئیتر ناتوانێت هەر سێ جۆری سووڕانەوە پێکەوە کۆنترۆڵ بکات: دەتوانێت خۆی ڕاست ڕابگرێت، بەڵام لەوانەیە لە کاتی دابەزیندا بە هێواشی بە دەوری خۆیدا بسووڕێتەوە (). ئەگەر زیادەی هەبێت و بۆ ئەمە دروست کرابێت، ئەمە بەسە بۆ ئەوەی بە سەلامەتی بنیشێتەوە.
So extra rotors give a chance, not a guarantee. Some professional drones also carry a parachute as another layer of redundancy.
کەواتە زیادە هەلێک دەدات، نەک گەرەنتی. هەندێک پیشەیی پەڕەشووتیش هەڵدەگرن وەک چینێکی تری .
Fixed-wing dronesدرۆنە باڵجێگیرەکان
A fixed-wing drone looks like a small aeroplane. Its wings make lift as air flows over them, so the motor only has to pull it forward. That is very efficient: a small electric fixed wing often flies an hour or more on one battery and covers much more ground than a multirotor. It is the favourite for mapping large farms, forests and roads. Its weakness: it must keep moving forward to stay up, so it cannot hover and cannot take off straight up.
لە فڕۆکەیەکی بچووک دەچێت. باڵەکانی کاتێک هەوا بەسەریاندا تێدەپەڕێت دروست دەکەن، بۆیە تەنیا دەبێت بەرەو پێشەوە ڕایبکێشێت. ئەمە زۆر کارایە: کارەبایی بچووک زۆرجار بە یەک کاتژمێرێک یان زیاتر دەفڕێت و زۆر زیاتر لە ڕووبەر دەبڕێت. بۆیە باشترین هەڵبژاردنە بۆ نەخشەکێشانی کێڵگەی گەورە، دارستان و ڕێگا. لاوازییەکەی: دەبێت هەمیشە بەرەو پێش بجووڵێت بۆ ئەوەی لە هەوادا بمێنێتەوە، بۆیە ناتوانێت لە هەوادا ڕاوەستێت و ناتوانێت ڕاست بەرەو سەرەوە هەڵبفڕێت.
Many people think fixed wings always need a runway. Only the big ones do. Small ones are thrown by hand or shot from a catapult (a launcher powered by a stretched elastic cord, a spring or compressed air). They come back by gliding onto their belly, under a parachute or into a net.
زۆر کەس وا دەزانن هەمیشە ڕێڕەوی فڕۆکەخانەیان پێویستە. تەنیا گەورەکانیان. بچووکەکان بە دەست هەڵدەدرێن یان بە ئامێری هاویشتن (catapult: ئامێرێک کە بە پەتی لاستیکیی کێشراو، فەنەر یان هەوای پەستێنراو کار دەکات) دەهاوێژرێن. بە خلیسکان لەسەر سکیان، بە پەڕەشووت یان بە چوونە ناو تۆڕێکەوە دەگەڕێنەوە.
Single-rotor helicoptersهەلیکۆپتەرە بێفڕۆکەوانەکان
An unmanned helicopter is built like a small real helicopter: one big main rotor on top and a small tail rotor. Why the tail rotor? When the engine turns the big rotor one way, the body is pushed to turn the other way (torque, Newton's third law). The tail rotor blows sideways and stops this twist; changing its push turns the nose left or right.
وەک هەلیکۆپتەرێکی ڕاستەقینەی بچووک دروست کراوە: سەرەکیی گەورە لە سەرەوە و بچووکی کلک. بۆچی کلک؟ کاتێک بزوێنەرەکە گەورەکە بە ئاراستەیەک دەسووڕێنێت، لەشەکە بە ئاراستەی پێچەوانە پاڵ دەنرێت (زەبر، ). کلک هەوا بەرەو لا فوو دەکات و ئەم بادانە ڕادەگرێت؛ گۆڕینی لووتی هەلیکۆپتەرەکە بەرەو چەپ یان ڕاست دەسووڕێنێت.
One big rotor moves a lot of air slowly, which is more efficient than several small rotors, so a helicopter can hover longer and lift heavier loads than a multirotor of similar size. Many use petrol engines, which let them fly longer than battery multirotors — for example when spraying rice fields. The price: the rotor head is complex (a part called the swashplate tilts the blades as they turn), so it needs more maintenance, and its long, fast blades are dangerous.
گەورە هەوایەکی زۆر بە هێواشی دەجووڵێنێت، کە لە چەند بچووک کاراترە، بۆیە هەلیکۆپتەر دەتوانێت لە هاوقەبارە ماوەیەکی درێژتر لە هەوادا ڕاوەستێت و باری قورستر هەڵبگرێت. زۆریان بزوێنەری بەنزینیان هەیە و بۆیە لە ، کە بە کار دەکەن، زیاتر دەفڕن — بۆ نموونە لە کاتی ڕشاندنی کێڵگەی برنجدا. نرخەکەی: سەری ئاڵۆزە (پارچەیەک بە ناوی swashplate پەڕەکان لە کاتی سووڕانەوەدا لار دەکاتەوە)، بۆیە زیاتری پێویستە و پەڕە درێژ و خێراکانی مەترسیدارن.
NASA's Ingenuity on Mars solved the twist another way: two rotors on one mast spun in opposite directions (a coaxial helicopter), so their twists cancelled and no tail rotor was needed.
Ingenuityـی NASA لەسەر مەریخ بە شێوەیەکی تر ئەم بادانەی چارەسەر کرد: دوو لەسەر یەک تەوەر بە ئاراستەی پێچەوانە دەسووڕانەوە (هەلیکۆپتەری هاوتەوەر)، بۆیە بادانەکانیان یەکتریان لادەبرد و پێویستی بە کلک نەبوو.
Hybrid VTOL: up like a multirotor, along like a planeVTOLـی تێکەڵ: وەک فرەپەروانە بەرز دەبێتەوە، وەک فڕۆکە دەڕوات
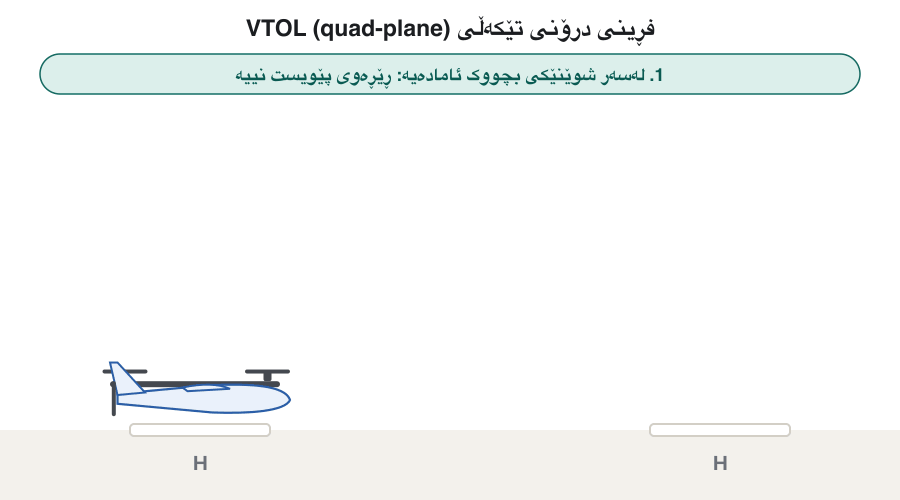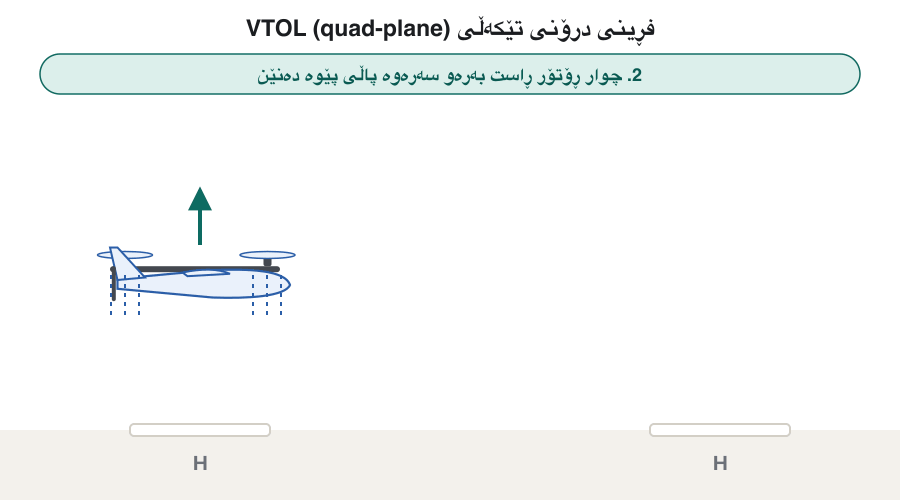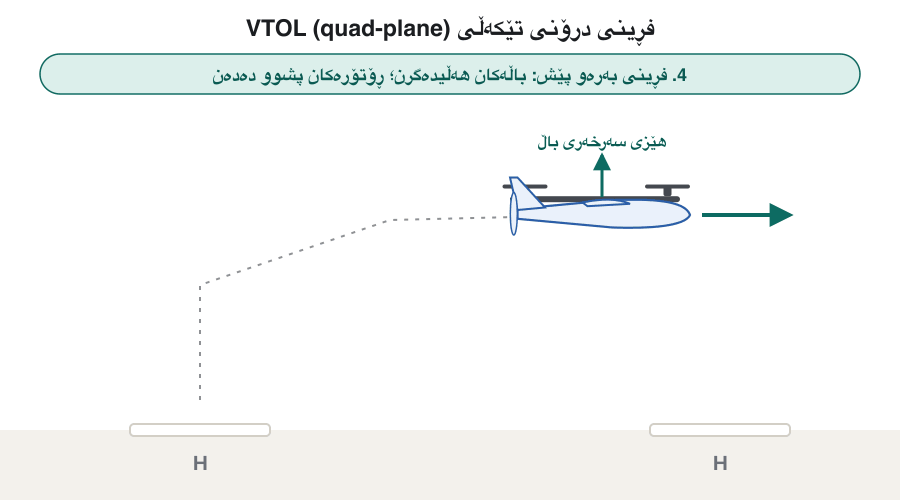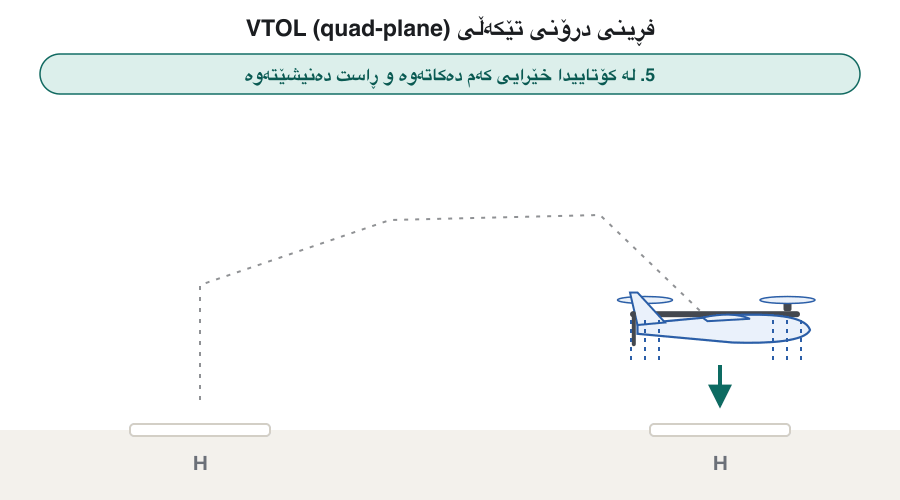
A hybrid VTOL drone (vertical take-off and landing) combines the two big ideas. It takes off straight up on rotors, like a multirotor, so it needs no runway or launcher. In the air it changes to forward flight — the transition — and then its wings carry it efficiently, like a fixed wing. At the end it slows down, changes back and lands vertically. The animation shows the most common kind, a quad-plane: four lift rotors for going up and down, and a propeller at the back for cruising.
تێکەڵی هەردوو بیرۆکە گەورەکە پێکەوە دەبەستێتەوە. بە ڕاست بەرەو سەرەوە هەڵدەفڕێت، وەک ، بۆیە پێویستی بە ڕێڕەو یان ئامێری هاویشتن نییە. لە ئاسماندا دەگۆڕێت بۆ فڕینی بەرەو پێش — ئەمە پێی دەوترێت گواستنەوە (transition) — پاشان باڵەکانی بە کارایی هەڵیدەگرن، وەک . لە کۆتاییدا خێرایی کەم دەکاتەوە، دەگەڕێتەوە بۆ دۆخی و بە ستوونی دەنیشێتەوە. باوترین جۆری پیشان دەدات، quad-plane: چوار بۆ بەرزبوونەوە و نیشتنەوە و لە دواوە بۆ فڕینی بەرەو پێش.
The cost: it carries parts it does not use all the time, so it is heavier, more expensive and harder to build and tune than either a multirotor or a fixed wing, and it flies a little less far than a pure fixed wing of the same size. Many of the electric air taxis tested in 2026 are big VTOL aircraft of this kind (Air taxis).
نرخەکەی: پارچەی هەڵدەگرێت کە هەموو کات بەکاریان ناهێنێت، بۆیە لە و قورستر و گرانترە و دروستکردن و ڕێکخستنی سەختترە، هەروەها کەمێک لە پەتیی هاوقەبارە کەمتر دوور دەفڕێت. زۆرێک لە کە لە ساڵی 2026دا تاقی دەکرێنەوە، فڕۆکەی کارەبایی و VTOLـی گەورەن لەم جۆرە (تەکسییە ئاسمانییەکان).
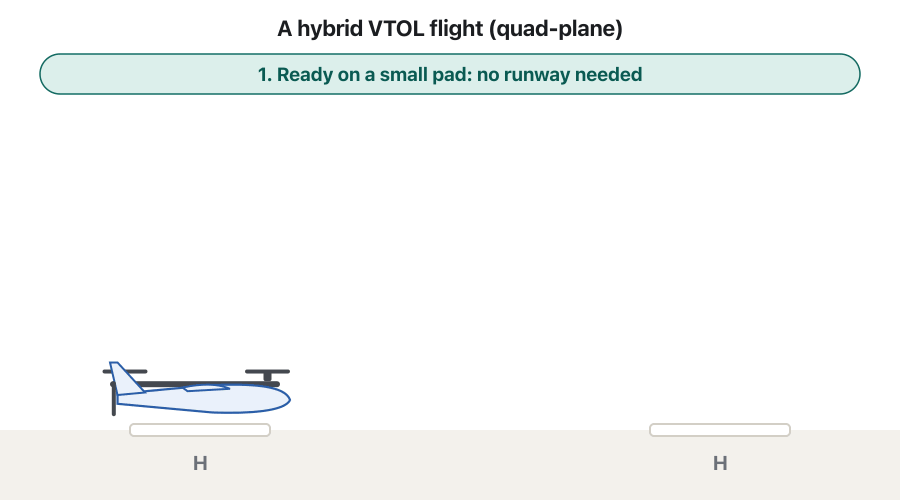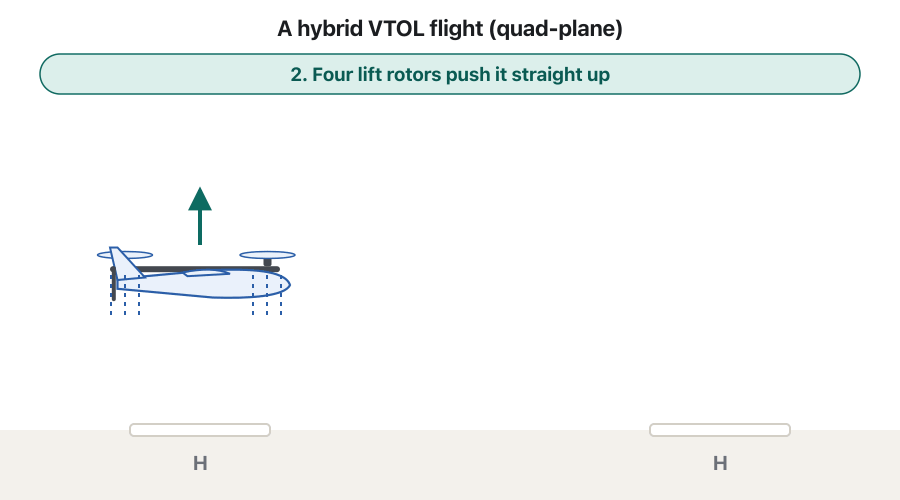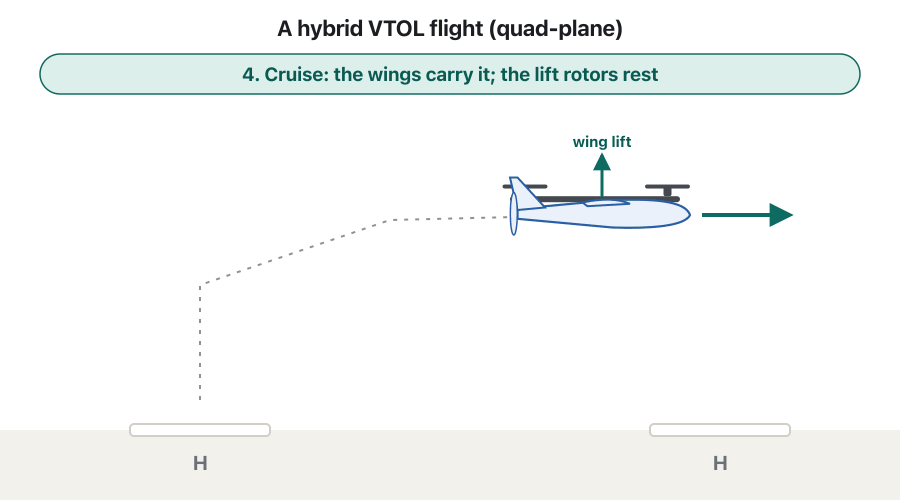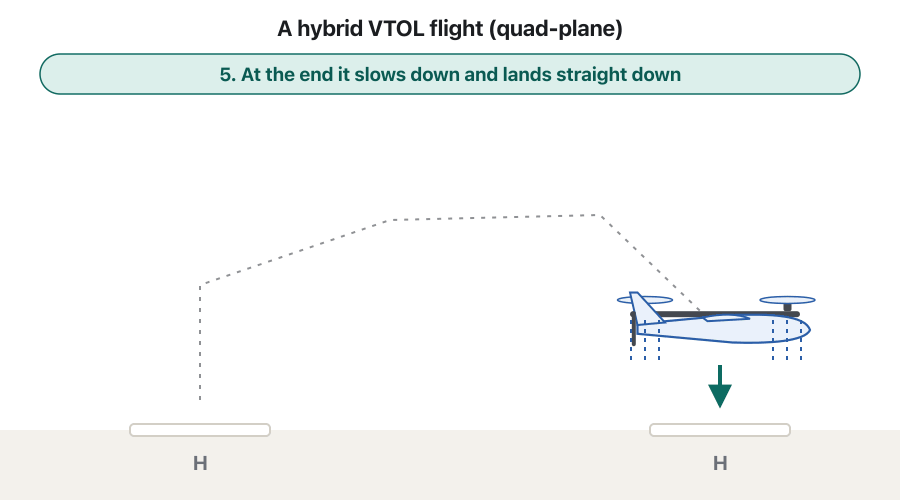
Hybrid VTOL: up like a multirotor, along like a planeVTOLـی تێکەڵ: وەک فرەپەروانە بەرز دەبێتەوە، وەک فڕۆکە دەڕوات
Three ways to build a hybrid VTOLسێ ڕێگا بۆ دروستکردنی VTOLـی تێکەڵ
- Quad-plane (standard VTOL): separate rotors for hovering and a separate propeller for cruising. It is the easiest to control, but it carries motors that rest during cruise.
- Tilt-rotor: the same rotors swivel through about 90°, pointing up to hover and forward to cruise. Fewer motors sit idle, but the tilting parts are complex.
- Tail-sitter: the whole aircraft stands on its tail to take off, then tips forward to fly on its wings. It is simple and robust, but hard to control in wind.
- quad-plane (VTOLـی ستاندارد): جیا بۆ و جیا بۆ فڕینی بەرەو پێش. کۆنترۆڵکردنی لە هەموویان ئاسانترە، بەڵام ئەو هەڵدەگرێت کە لە کاتی فڕینی بەرەو پێشدا پشوو دەدەن.
- tilt-rotor: هەمان نزیکەی 90° دەسووڕێنەوە: بۆ ڕاوەستان ڕوویان لە سەرەوەیە و بۆ فڕینی بەرەو پێش ڕوویان لە پێشەوە. بێکار کەمترە، بەڵام پارچەکانی لارکردنەوە ئاڵۆزن.
- tail-sitter: هەموو فڕۆکەکە لەسەر کلکی ڕادەوەستێت بۆ هەڵفڕین، پاشان بەرەو پێش دادەنەوێت و بە باڵەکانی دەفڕێت. سادە و بەهێزە، بەڵام لە بادا کۆنترۆڵکردنی سەختە.
In all three, the flight controller manages the transition, either when the pilot flips a switch or automatically during a mission.
لە هەر سێکیاندا گواستنەوەکە بەڕێوە دەبات، یان کاتێک فڕۆکەوانەکە کلیلێک دەگۆڕێت یان بە شێوەی خۆکار لە کاتی ئەرکێکدا.
Side by sideبەراوردکردن
No drone type is best at everything. Compare them before you choose (typical small civil drones as of 2026; exact numbers depend on the model):
هیچ جۆرێکی لە هەموو شتێکدا باشترین نییە. پێش هەڵبژاردن بەراوردیان بکە (بە پێی مەدەنییە بچووکە باوەکان تا ساڵی 2026؛ ژمارە وردەکان بە پێی مۆدێلەکە دەگۆڕێن):
| Typeجۆر | Hovers?لە هەوادا ڕادەوەستێت؟ | Flight time and rangeماوە و دووریی فڕین | Payloadبار | Space to take offشوێنی هەڵفڕین | Complexityئاڵۆزی |
|---|---|---|---|---|---|
| Multirotor (quad, hexa, octo) (چوار، شەش، هەشت) | Yes, very preciselyبەڵێ، زۆر بە وردی | Short: often 20–40 minکورت: زۆرجار 20 تا 40 خولەک | Small to large (more rotors, more lift)بچووک تا گەورە ( زیاتر، زیاتر) | Very smallزۆر بچووک | Simple mechanicsمیکانیکی سادە |
| Fixed wing | Noنەخێر | Long: often an hour or more, farدرێژ: زۆرجار کاتژمێرێک یان زیاتر، دوور | Light to mediumسووک تا مامناوەند | Hand, catapult or runway; open space to landدەست، ئامێری هاویشتن یان ڕێڕەو؛ شوێنی کراوە بۆ نیشتنەوە | Simple, but harder to fly and landسادە، بەڵام فڕاندن و نیشاندنەوەی سەختترە |
| Single-rotor helicopter | Yesبەڵێ | Medium; longer with a petrol engineمامناوەند؛ بە بزوێنەری بەنزین درێژتر | Heavyقورس | Smallبچووک | Complex rotor head; dangerous bladesسەری ئاڵۆز؛ پەڕەی مەترسیدار |
| Hybrid VTOLVTOLـی تێکەڵ | Yes, but less efficientlyبەڵێ، بەڵام بە کارایی کەمتر | Long, a little less than a fixed wingدرێژ، کەمێک کەمتر لە | Light to mediumسووک تا مامناوەند | Very smallزۆر بچووک | Most complex and expensiveئاڵۆزترین و گرانترین |
Which drone for which job?کام درۆن بۆ کام کار؟
Choose by asking three questions: Must it hover or work in a small space? How far or how long must it fly? How heavy is the load? The map places the four families by the first two questions.
بە سێ پرسیار هەڵبژێرە: ئایا دەبێت لە هەوادا ڕاوەستێت یان لە شوێنێکی بچووکدا کار بکات؟ دەبێت چەند دوور یان چەند درێژ بفڕێت؟ بارەکە چەند قورسە؟ نەخشەکە چوار خێزانەکە بە پێی دوو پرسیاری یەکەم دادەنێت.
Common mistakesهەڵە باوەکان
| Mistakeهەڵە | Betterباشتر |
|---|---|
| "More rotors make a drone more stable."« زیاتر جێگیرتر دەکات.» | Stability comes mainly from the flight controller. More rotors add lift and redundancy, but also weight and cost.جێگیری بە زۆری لە دێت. زیاتر و زیاد دەکات، بەڵام کێش و تێچووش. |
| "All the rotors of a quadcopter spin the same way."«هەموو بە یەک ئاراستە دەسووڕێنەوە.» | Neighbouring rotors spin in opposite directions so that their torques cancel.دوو تەنیشت یەک بە پێچەوانەی یەک دەسووڕێنەوە بۆ ئەوەی یەکتر لاببەن. |
| "Fixed-wing drones always need a runway."« هەمیشە ڕێڕەویان پێویستە.» | Only big ones. Small ones are hand- or catapult-launched and land on their belly, by parachute or in a net.تەنیا گەورەکانیان. بچووکەکان بە دەست یان بە ئامێری هاویشتن هەڵدەدرێن و لەسەر سک، بە پەڕەشووت یان لە تۆڕدا دەنیشنەوە. |
| "A fixed wing can stop in the air to take a photo."« دەتوانێت لە ئاسماندا بوەستێت بۆ وێنەگرتن.» | It must keep moving forward. To hover, use a multirotor, a helicopter or a VTOL drone.دەبێت هەمیشە بەرەو پێش بجووڵێت. بۆ ، هەلیکۆپتەر یان VTOL بەکار بهێنە. |
| "A hexacopter never falls when a motor fails."« هەرگیز ناکەوێت کاتێک تێکدەچێت.» | It has a chance to land if it has spare thrust and its software handles the failure; it is not guaranteed.هەلی نیشتنەوەی هەیە ئەگەر زیادەی هەبێت و تێکچوونەکە بەڕێوە ببات؛ گەرەنتی نییە. |
| "A helicopter needs its tail rotor to go up."«هەلیکۆپتەر بۆ بەرزبوونەوە پێویستی بە کلکە.» | The main rotor lifts it; the tail rotor stops the body from spinning and steers the nose. سەرەکی بەرزی دەکاتەوە؛ کلک ڕێگە نادات لەشەکە بسووڕێتەوە و لووتەکە ئاراستە دەکات. |
Exercisesڕاهێنانەکان
Look at the six drones. For each number, name the family (or the layout) and say whether it can hover.
سەیری شەش بکە. بۆ هەر ژمارەیەک خێزانەکەی (یان شێوەی دانانەکەی) ناو ببە و بڵێ ئایا دەتوانێت لە هەوادا ڕاوەستێت.
Show answerوەڵامەکە پیشان بدە
- 1: octocopter (multirotor) — hovers.
- 2: single-rotor unmanned helicopter — hovers.
- 3: fixed-wing drone — cannot hover.
- 4: tail-sitter (hybrid VTOL) — hovers for take-off and landing.
- 5: quadcopter in the X layout (multirotor) — hovers.
- 6: quad-plane (hybrid VTOL) — hovers for take-off and landing.
- 1: () — لە هەوادا ڕادەوەستێت.
- 2: — لە هەوادا ڕادەوەستێت.
- 3: — ناتوانێت لە هەوادا ڕاوەستێت.
- 4: tail-sitter (VTOLـی تێکەڵ) — بۆ هەڵفڕین و نیشتنەوە لە هەوادا ڕادەوەستێت.
- 5: بە شێوەی X () — لە هەوادا ڕادەوەستێت.
- 6: quad-plane (VTOLـی تێکەڵ) — بۆ هەڵفڕین و نیشتنەوە لە هەوادا ڕادەوەستێت.
Draw an X quadcopter from above. Mark the front, then mark each rotor CW or CCW.
X لە سەرەوە بکێشە. پێشەوە دیاری بکە، پاشان هەر بە CW یان CCW دیاری بکە.
Hintئاماژە
Neighbours are always different; opposite corners are the same.
دوو تەنیشت یەک هەمیشە جیاوازن؛ دوو گۆشەی بەرامبەر وەک یەکن.
Show answerوەڵامەکە پیشان بدە
One common set-up (used by ArduPilot and PX4): front-left CW, front-right CCW, rear-right CW, rear-left CCW. The mirror image is also correct, as long as neighbours differ and the props match the motors.
یەکێک لە ڕێکخستنە باوەکان (کە ArduPilot و PX4 بەکاری دەهێنن): پێشەوەی چەپ CW، پێشەوەی ڕاست CCW، دواوەی ڕاست CW، دواوەی چەپ CCW. وێنەی ئاوێنەیی ئەمەش ڕاستە، بە مەرجێک دوو تەنیشت یەک جیاواز بن و لەگەڵ بگونجێن.
For each job, choose a drone family and give one reason: (a) carrying a 2 kg medicine box 40 km to a mountain village with no landing strip; (b) inspecting the blades of a wind turbine; (c) surveying 30 km of a new road; (d) flying in the very thin air of Mars, where there is no runway and nobody can launch it by hand.
بۆ هەر کارێک خێزانێکی هەڵبژێرە و هۆکارێک بڵێ: (أ) گەیاندنی سندوقێکی 2 کیلۆگرامیی دەرمان بۆ گوندێکی شاخاوی کە 40 کیلۆمەتر دوورە و شوێنی نیشتنەوەی نییە؛ (ب) پشکنینی پەڕەکانی تۆربینێکی با؛ (ج) ڕووپێوی 30 کیلۆمەتر لە ڕێگایەکی نوێ؛ (د) فڕین لە هەوای زۆر تەنکی مەریخدا، کە ڕێڕەوی نییە و کەس نییە بە دەست هەڵیبدات.
Show answerوەڵامەکە پیشان بدە
- (a) Hybrid VTOL: wings for the 40 km trip, vertical landing in the village.
- (b) Multirotor (quadcopter): it must hover close to the blades.
- (c) Fixed wing (or VTOL): a long, straight route needs efficient flight.
- (d) A helicopter that takes off vertically — NASA chose a coaxial one, Ingenuity, with no tail rotor.
- (أ) VTOLـی تێکەڵ: باڵ بۆ ڕێگای 40 کیلۆمەترییەکە و نیشتنەوەی ستوونی لە گوندەکەدا.
- (ب) (): دەبێت لە نزیک پەڕەکان لە هەوادا ڕاوەستێت.
- (ج) (یان VTOL): ڕێگایەکی درێژ و ڕاست فڕینی کارای پێویستە.
- (د) هەلیکۆپتەرێک کە بە ستوونی هەڵدەفڕێت — NASA هەلیکۆپتەرێکی هاوتەوەری هەڵبژارد، Ingenuity، کە کلکی نییە.
Summaryپوختە
- Four families: multirotors, fixed wings, single-rotor helicopters and hybrid VTOL.
- Quadcopters (+ or X) are the most common small civil drones; neighbouring rotors spin opposite ways so their torques cancel.
- Hexa, octo, X8 and Y6 add lift and redundancy, at the cost of weight, energy and money; stability comes from the flight controller.
- Fixed wings fly long and far but cannot hover; small ones need no runway.
- A helicopter's tail rotor stops the body spinning; coaxial rotors cancel the twist instead.
- Hybrid VTOL drones take off like multirotors and cruise on wings: quad-plane, tilt-rotor or tail-sitter.
- چوار خێزان: ، ، و VTOLـی تێکەڵ.
- (+ یان X) باوترین مەدەنییە بچووکەکانن؛ دوو تەنیشت یەک بە پێچەوانەی یەک دەسووڕێنەوە بۆ ئەوەی یەکتر لاببەن.
- شەش، هەشت، X8 و Y6 و زیاد دەکەن، بە نرخی کێش، وزە و پارە؛ جێگیری لە دێت.
- درێژ و دوور دەفڕن بەڵام ناتوانن لە هەوادا ڕاوەستن؛ بچووکەکانیان ڕێڕەویان ناوێت.
- کلکی هەلیکۆپتەر ڕێگە نادات لەشەکە بسووڕێتەوە؛ هاوتەوەرەکان لەبری ئەوە بادانەکە لادەبەن.
- تێکەڵەکانی وەک هەڵدەفڕن و بە باڵ دەڕۆن: quad-plane، tilt-rotor یان tail-sitter.
Why can a fixed-wing drone fly so much longer than a quadcopter?بۆچی درۆنی باڵجێگیر دەتوانێت زۆر زیاتر لە چوارپەروانە بفڕێت؟
Its wings make lift from the air flowing past them, so the motor only pushes it forward. A quadcopter must hold its whole weight up with its rotors all the time.
باڵەکانی لەو هەوایەی بە لایاندا تێدەپەڕێت دروست دەکەن، بۆیە تەنیا بەرەو پێش پاڵی پێوە دەنێت. دەبێت هەمیشە بە هەموو کێشی خۆی ڕابگرێت.
What do more rotors give, and what do they cost?ڕۆتۆری زیاتر چی دەدات و تێچووی چییە؟
More lift and a chance to land after a motor failure (redundancy); but more weight, energy use and money, and often a shorter flight.
زیاتر و هەلی نیشتنەوە دوای تێکچوونی ()؛ بەڵام کێش، و پارەی زیاتر و زۆرجار فڕینی کورتتر.
Name the three kinds of hybrid VTOL drone.سێ جۆری درۆنی تێکەڵی VTOL ناو ببە.
Quad-plane (separate lift rotors and a cruise propeller), tilt-rotor (rotors that tilt) and tail-sitter (the whole aircraft tips forward).
quad-plane ( جیای هەڵگرتن و فڕینی بەرەو پێش)، tilt-rotor ( لار دەبنەوە) و tail-sitter (هەموو فڕۆکەکە بەرەو پێش لار دەبێتەوە).
Lesson complete!وانەکە تەواو بوو!
Well done. Review the key terms, then go on to the next lesson.دەستخۆش. سەیرێکی زاراوە سەرەکییەکان بکەرەوە، پاشان بڕۆ بۆ وانەی داهاتوو.
Key termsزاراوە سەرەکییەکان
Inside a Drone: Frame, Motors, ESCs and Propellersناو درۆن: چوارچێوەی درۆن، ماتۆڕەکان، کۆنترۆڵکەرەکانی خێرایی و پەروانەکان
Related lecturesوانە پەیوەندیدارەکان
- How a Quadcopter Flies: Forces, Torque, Pitch, Roll and Yawچوارپەروانە چۆن دەفڕێت: هێزەکان، زەبر، لێژی، لاربوونەوە و سووڕانەوەی ئاسۆیی
- Inside a Drone: Frame, Motors, ESCs and Propellersناو درۆن: چوارچێوەی درۆن، ماتۆڕەکان، کۆنترۆڵکەرەکانی خێرایی و پەروانەکان
- The Flight Controller: Sensors, Control Loops and Autopilotsکۆنترۆڵکەری فڕین: هەستەوەرەکان، خولەکانی کۆنترۆڵ و فڕۆکەوانی خۆکار
- Drones at Work: Farms, Building Sites, Emergencies, Media and Deliveryدرۆنەکان لە کاردا: کێڵگە، شوێنی بیناسازی، فریاکەوتن، میدیا و گەیاندن
- Autonomy, Swarms, Air Taxis and the Future of Dronesسەربەخۆیی، ڕەوەکانی درۆن، تەکسییە ئاسمانییەکان و داهاتووی درۆنەکان
- Emerging Technologies: IoT, VR/AR, Robots and Blockchainتەکنەلۆجیا نوێیەکان: ئینتەرنێتی شتەکان، ڕاستیی گریمانەیی/ڕاستیی زیادکراو، ڕۆبۆتەکان و بلۆکچەین
References and further readingسەرچاوەکان و خوێندنەوەی زیاتر
- PX4 User Guide: Basic concepts (vehicle types, minimum sensors)
- PX4 User Guide: VTOL (standard VTOL, tiltrotor, tailsitter)
- ArduPilot Copter: Connect ESCs and motors (motor order, CW and CCW propellers)
- ArduPilot Plane: QuadPlane overview
- Du, Quan and Cai (2015): Controllability analysis and degraded control for a class of hexacopters subject to rotor failures, J. Intelligent & Robotic Systems 78(1)
- Mueller and D'Andrea (2014): Stability and control of a quadrocopter despite the complete loss of one, two, or three propellers, IEEE ICRA 2014
- Ramesh and Muruga Lal Jeyan (2022): Comparative analysis of fixed-wing, rotary-wing and hybrid mini UAS, INCAS Bulletin 14(1)
- Penn State GEOG 892 (Unmanned Aerial Systems): Launch and recovery
- NASA JPL: Mastcam-Z captures Ingenuity's blades spinning (two counter-rotating rotors, about 2,400 rpm)
- NASA Science: Ingenuity Mars Helicopter
This lecture is a first edition. The Kurdish text and terminology are waiting for review by Kurdish IT teachers.ئەم وانەیە چاپی یەکەمە. دەقە کوردییەکە و زاراوەکانی چاوەڕێی پێداچوونەوەی مامۆستایانی کوردی بواری IT ن.